

DROID_ERROR_AUTO_KIOSK_BOTTOM_WALL_TAG_NOT_DETECTED
Applicable alarms (1)
Likely outcomes — click to expand
Based on 0 missions where this alarm fired in the last 90 days as of 2026-10-13
Aggregated from fleet operations and refreshed daily. Individual outcomes may vary by site and configuration.
Background
Section titled “Background”In order to ensure a clean Zipping Point pickup, the Droid will not attempt to close doors on a package unless it detects the bottom wall tag. This error code indicates that the Droid was expecting to see the bottom wall tag, but it didn’t. This may happen if the platform didn’t lower all the way or if the cameras were unable to detect the wall tag due to an obstruction, dirty lens, lack of lighting, or bad calibration.
Note: At night, the center camera has no IR illumination so the videos will appear dark until the droid is inside the ZP where lights should be on. The right and left cameras have IR illumination but the videos will still be dark until the droid approaches the ZP.
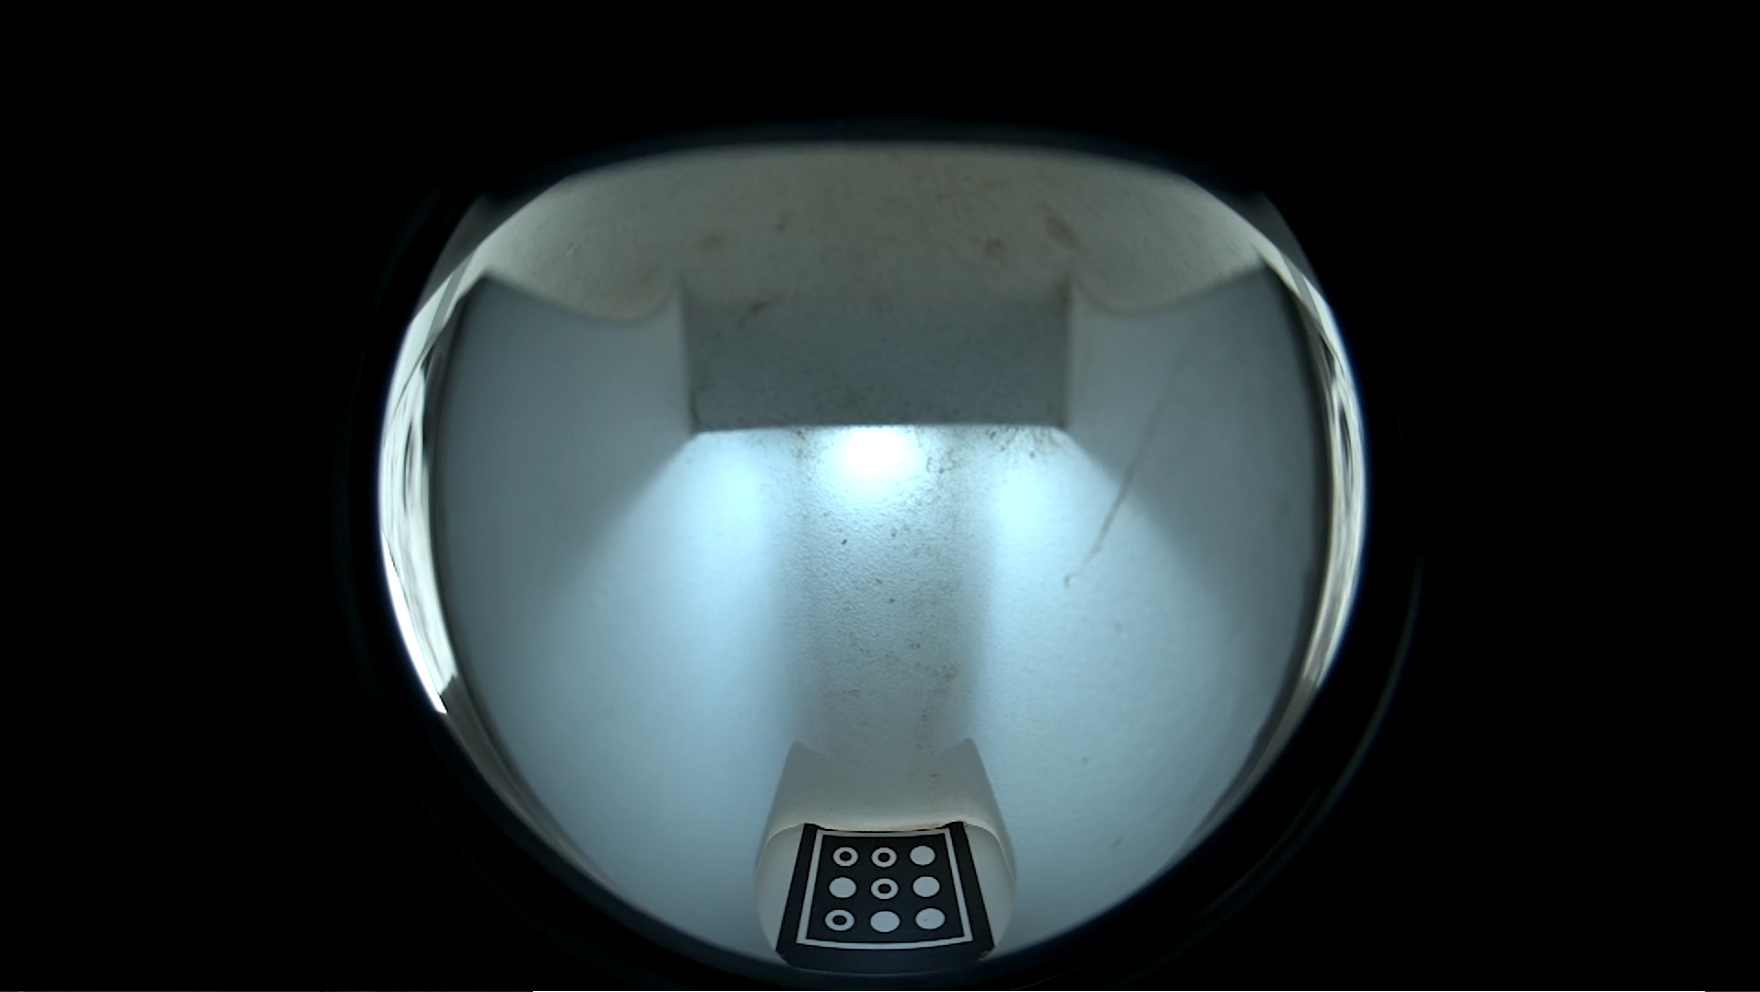
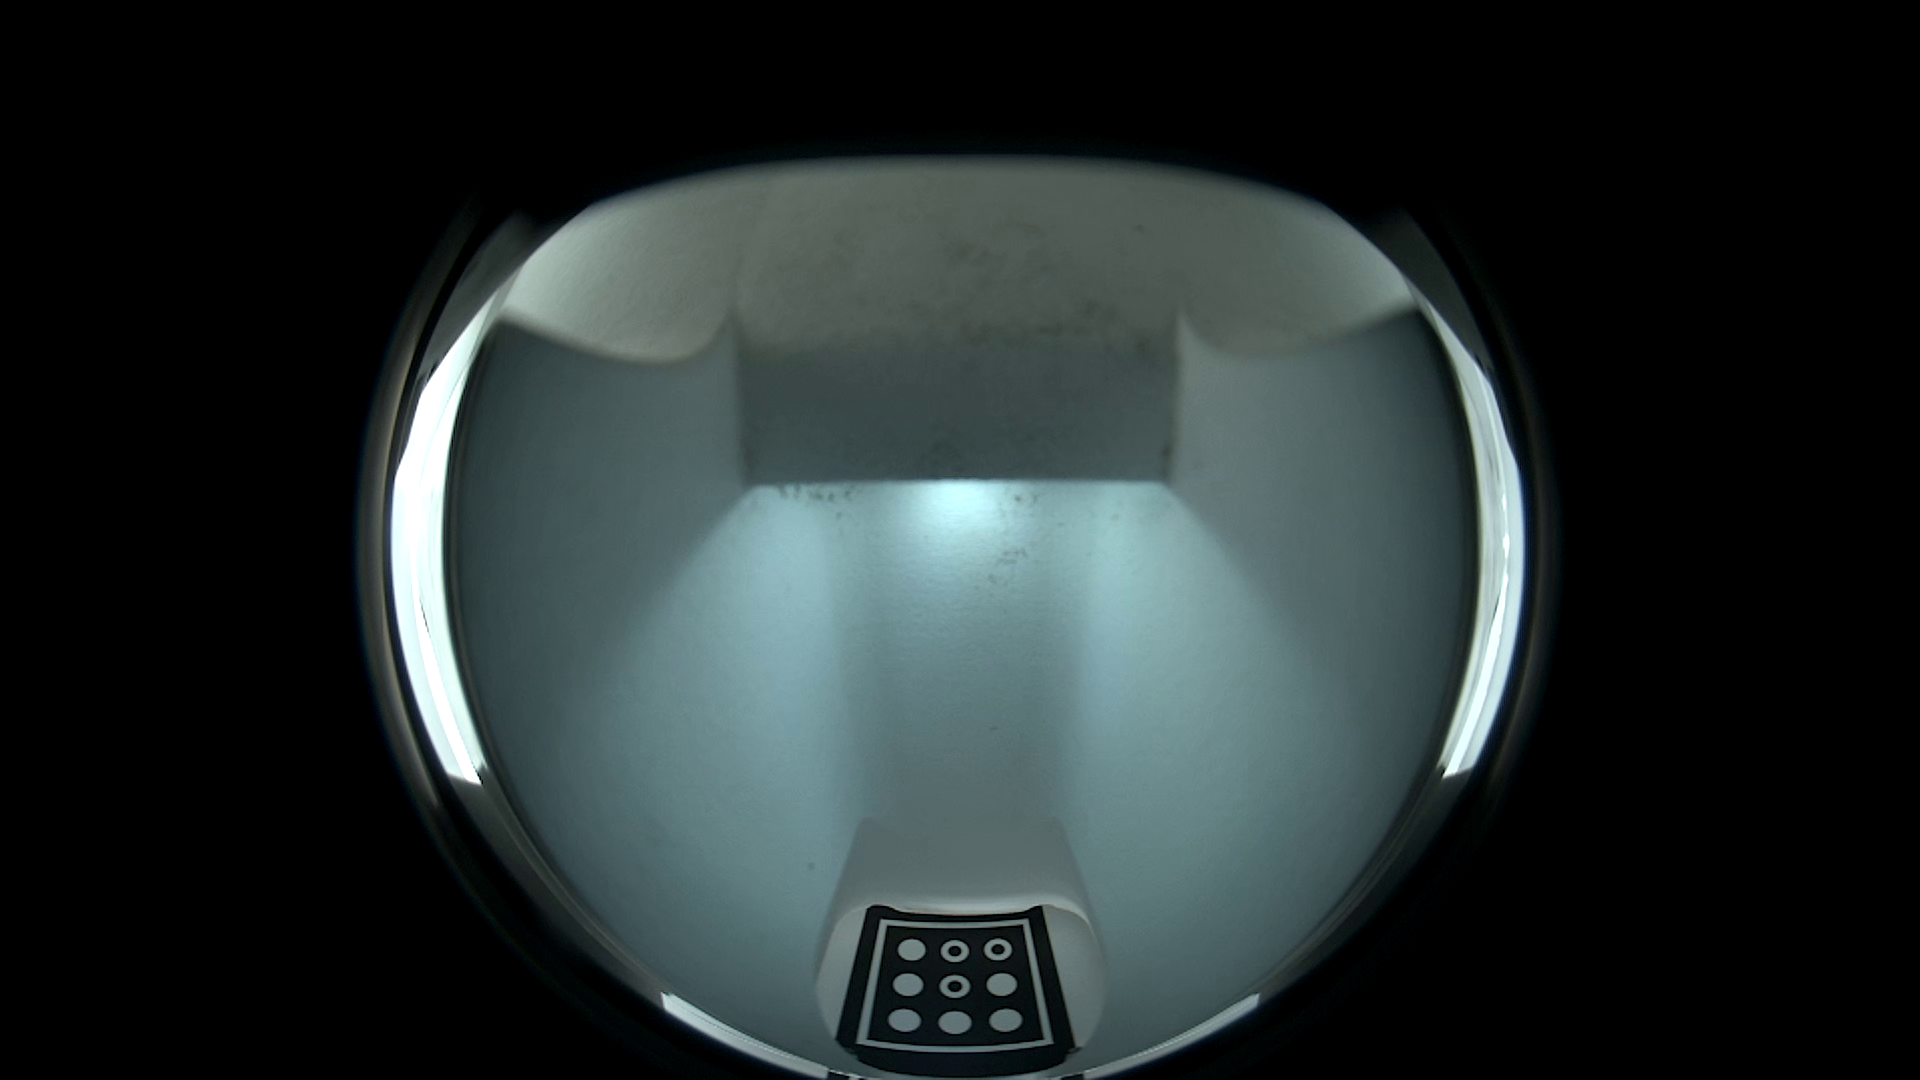
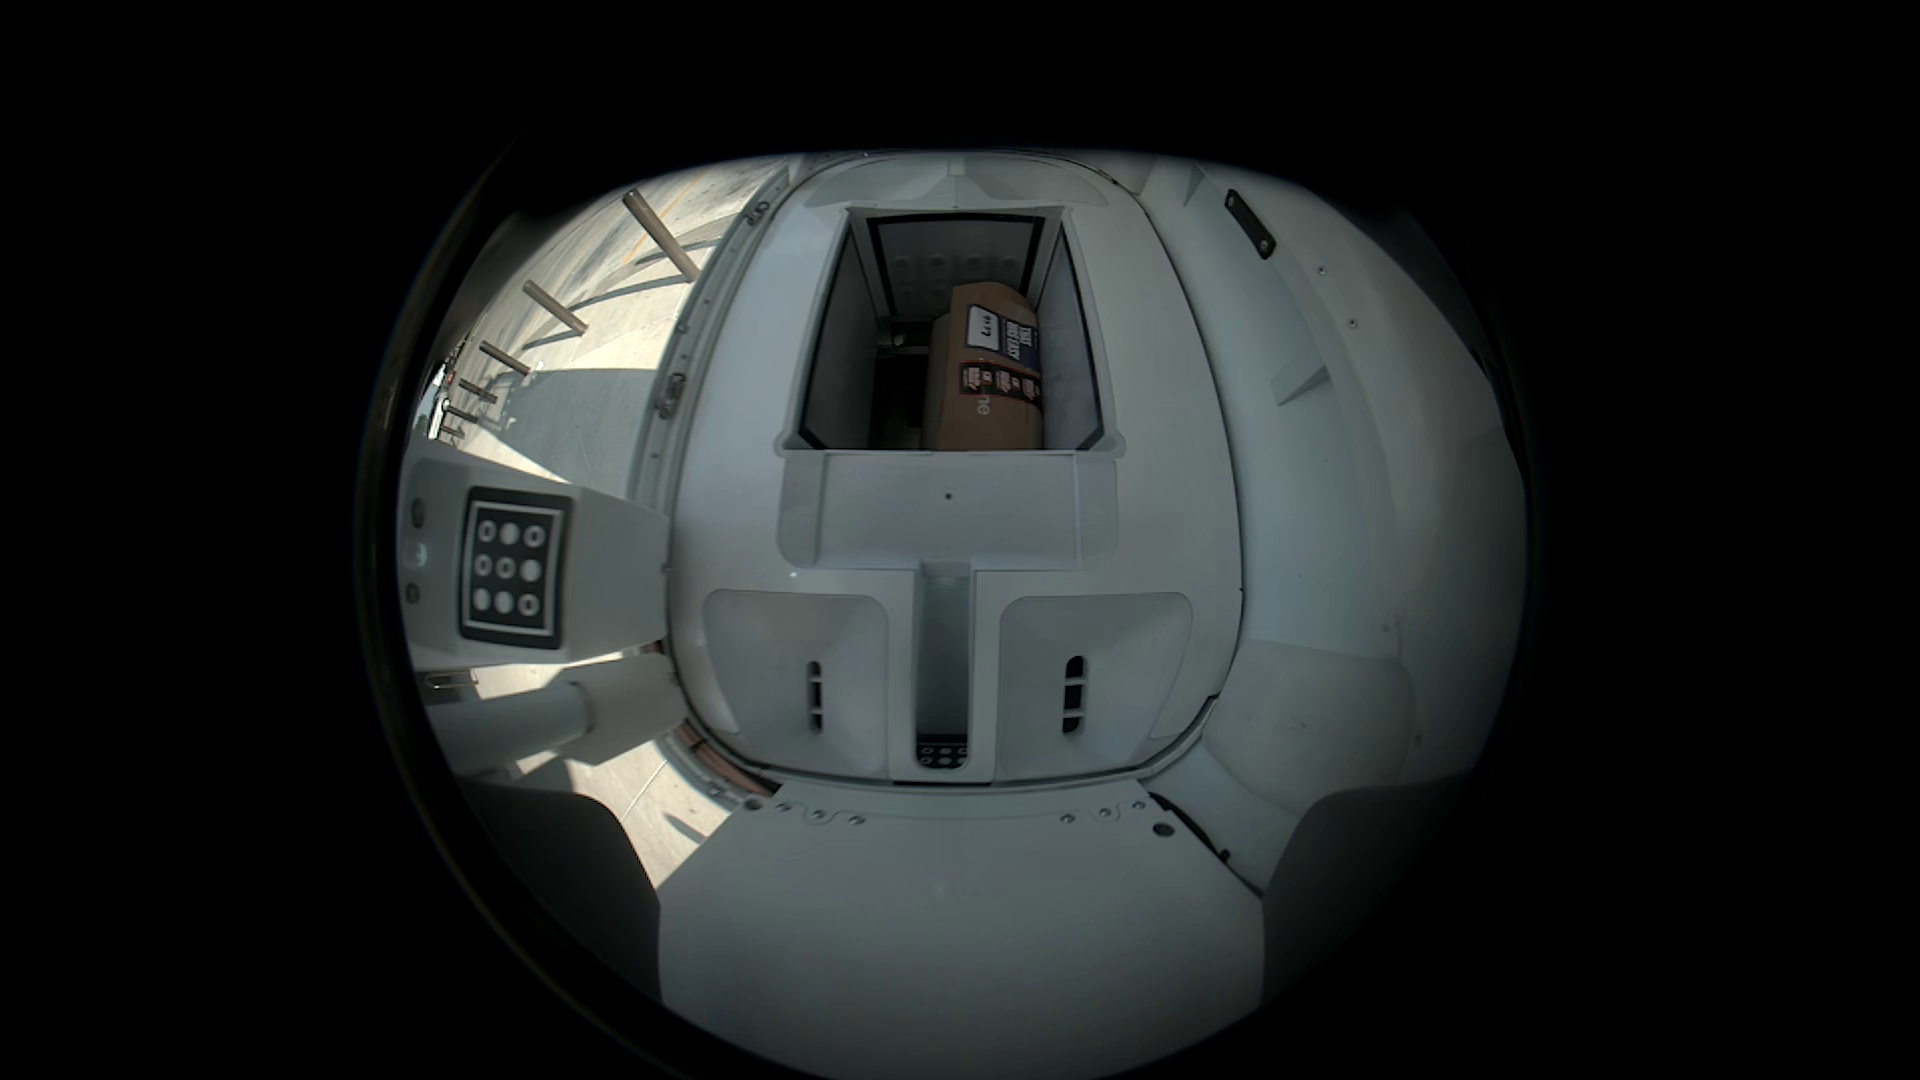
Example of a clearly visible bottom wall tag with the correct orientation and the platform fully lowered.
Troubleshooting Steps
Section titled “Troubleshooting Steps”Look at the video logs from the droid center camera. If the logs from the current mission are not available, try the previous mission or the one before that.
graph TD
    were-zipping-point-lights-on{"<small><b>Step 1</b></small><br/>Question: ***Is the inside of the kiosk well-il..."}
    is-camera-clean{"<small><b>Step 2</b></small><br/>Question: ***Is the camera clean and free of di..."}
    power-cycle-zipping-point-lights{"<small><b>Step 3</b></small><br/>Question: Assign the 'Ranger: Power Cycle Zippi..."}
    return-zipping-point-to-service["<small><b>Step 4</b></small><br/>Action: Return the zipping point to service."]
    escalate-to-zipping-point-on-call{{"<small><b>Step 5</b></small><br/>Escalation: Escalate to Zipping Point On Call."}}
    did-platform-lower-all-the-way{"<small><b>Step 6</b></small><br/>Question: ***Did the platform lower all the way..."}
    was-magic-carpet-already-collapsed{"<small><b>Step 7</b></small><br/>Question: ***Was the magic carpet nominal befor..."}
    inspect-inner-mech{"<small><b>Step 8</b></small><br/>Question: Assign the V4 Zipping Point: Inspect..."}
    return-zipping-point-to-service-after-inner-mech-inspection["<small><b>Step 9</b></small><br/>Action: Return the zipping point to service."]
    escalate-to-zipping-point-on-call-after-inner-mech-inspection{{"<small><b>Step 10</b></small><br/>Escalation: Escalate to Zipping Point On Call."}}
    perform-platform-drawer-inspection{"<small><b>Step 11</b></small><br/>Question: Assign the Perform Go/NoGo Testhtt..."}
    escalate-to-zipping-point-on-call-after-nominal-platform-forces{{"<small><b>Step 12</b></small><br/>Escalation: Escalate to Zipping Point On Call."}}
    adjust-platform-tension["<small><b>Step 13</b></small><br/>Action: Assign the 'V4 Zipping Point: Adjust ..."]
    is-bottom-wall-tag-correct{"<small><b>Step 14</b></small><br/>Question: ***Is the bottom wall tag in the corr..."}
    replace-drawer-fiducial["<small><b>Step 15</b></small><br/>Action: Assign an ad-hoc work order titled 'R..."]
    create-dirty-camera-discrepancy["<small><b>Step 16</b></small><br/>Action: Return the zipping point to service. ..."]
    does-invalid-calibration-jump-true{"<small><b>Step 17</b></small><br/>Question: ***Is the calibration valid throughou..."}
    return-zipping-point-service-calibrate-droid["<small><b>Step 18</b></small><br/>Action: Return the zipping point to service a..."]
    escalate-to-p2-navigation-on-call{{"<small><b>Step 19</b></small><br/>Escalation: Escalate to P2 Nav On Call."}}
    were-zipping-point-lights-on -->|Yes| is-camera-clean
    were-zipping-point-lights-on -->|No| power-cycle-zipping-point-lights
    is-camera-clean -->|Yes| did-platform-lower-all-the-way
    is-camera-clean -->|No| create-dirty-camera-discrepancy
    power-cycle-zipping-point-lights -->|YES| return-zipping-point-to-service
    power-cycle-zipping-point-lights -->|NO| escalate-to-zipping-point-on-call
    did-platform-lower-all-the-way -->|Yes| is-bottom-wall-tag-correct
    did-platform-lower-all-the-way -->|No| was-magic-carpet-already-collapsed
    was-magic-carpet-already-collapsed -->|Yes| perform-platform-drawer-inspection
    was-magic-carpet-already-collapsed -->|No| inspect-inner-mech
    inspect-inner-mech -->|Yes| return-zipping-point-to-service-after-inner-mech-inspection
    inspect-inner-mech -->|No| escalate-to-zipping-point-on-call-after-inner-mech-inspection
    perform-platform-drawer-inspection -->|YES| escalate-to-zipping-point-on-call-after-nominal-platform-forces
    perform-platform-drawer-inspection -->|NO| adjust-platform-tension
    is-bottom-wall-tag-correct -->|Yes| does-invalid-calibration-jump-true
    is-bottom-wall-tag-correct -->|No| replace-drawer-fiducial
    does-invalid-calibration-jump-true -->|Yes| escalate-to-p2-navigation-on-call
    does-invalid-calibration-jump-true -->|No| return-zipping-point-service-calibrate-droid
    style were-zipping-point-lights-on fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
    style is-camera-clean fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
    style power-cycle-zipping-point-lights fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
    style return-zipping-point-to-service fill:#dcfce7,stroke:#22c55e,color:#14532d
    style escalate-to-zipping-point-on-call fill:#fef3c7,stroke:#f59e0b,color:#78350f
    style did-platform-lower-all-the-way fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
    style was-magic-carpet-already-collapsed fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
    style inspect-inner-mech fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
    style return-zipping-point-to-service-after-inner-mech-inspection fill:#dcfce7,stroke:#22c55e,color:#14532d
    style escalate-to-zipping-point-on-call-after-inner-mech-inspection fill:#fef3c7,stroke:#f59e0b,color:#78350f
    style perform-platform-drawer-inspection fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
    style escalate-to-zipping-point-on-call-after-nominal-platform-forces fill:#fef3c7,stroke:#f59e0b,color:#78350f
    style adjust-platform-tension fill:#dcfce7,stroke:#22c55e,color:#14532d
    style is-bottom-wall-tag-correct fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
    style replace-drawer-fiducial fill:#dcfce7,stroke:#22c55e,color:#14532d
    style create-dirty-camera-discrepancy fill:#dcfce7,stroke:#22c55e,color:#14532d
    style does-invalid-calibration-jump-true fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
    style return-zipping-point-service-calibrate-droid fill:#dcfce7,stroke:#22c55e,color:#14532d
    style escalate-to-p2-navigation-on-call fill:#fef3c7,stroke:#f59e0b,color:#78350f
Hover or focus a block to preview it. Select the block to keep the preview open.
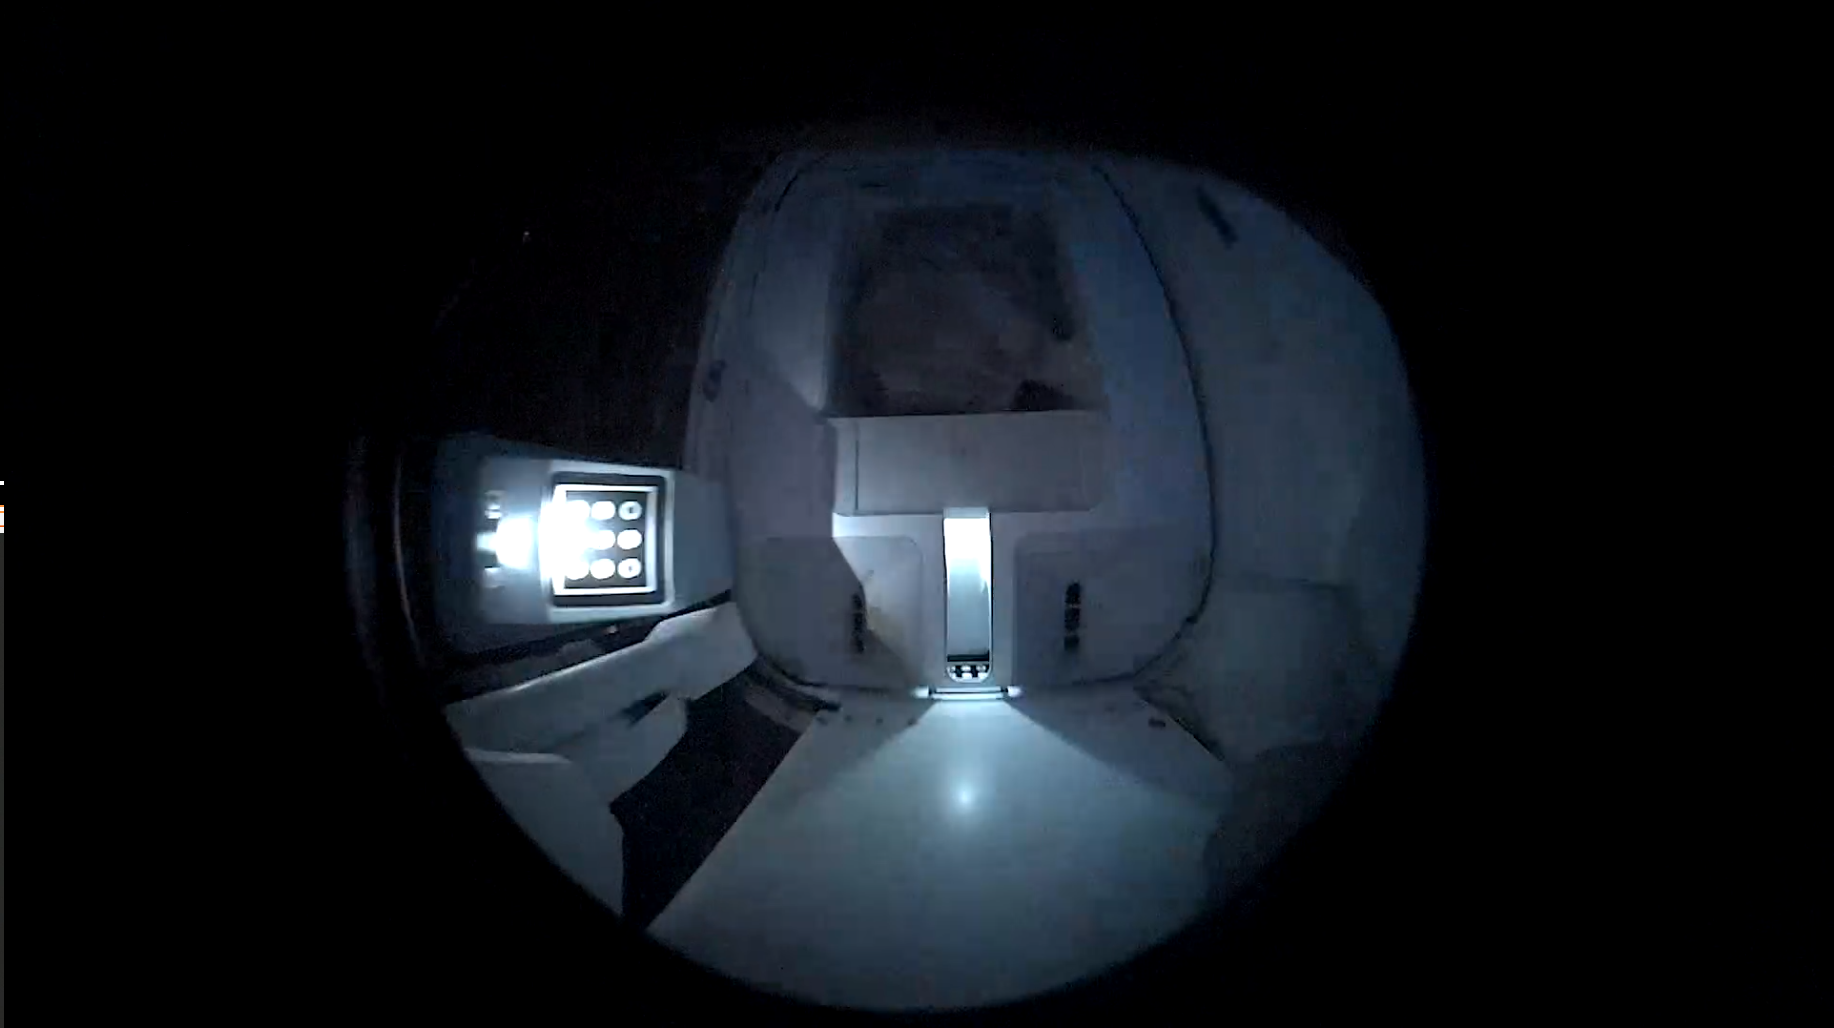
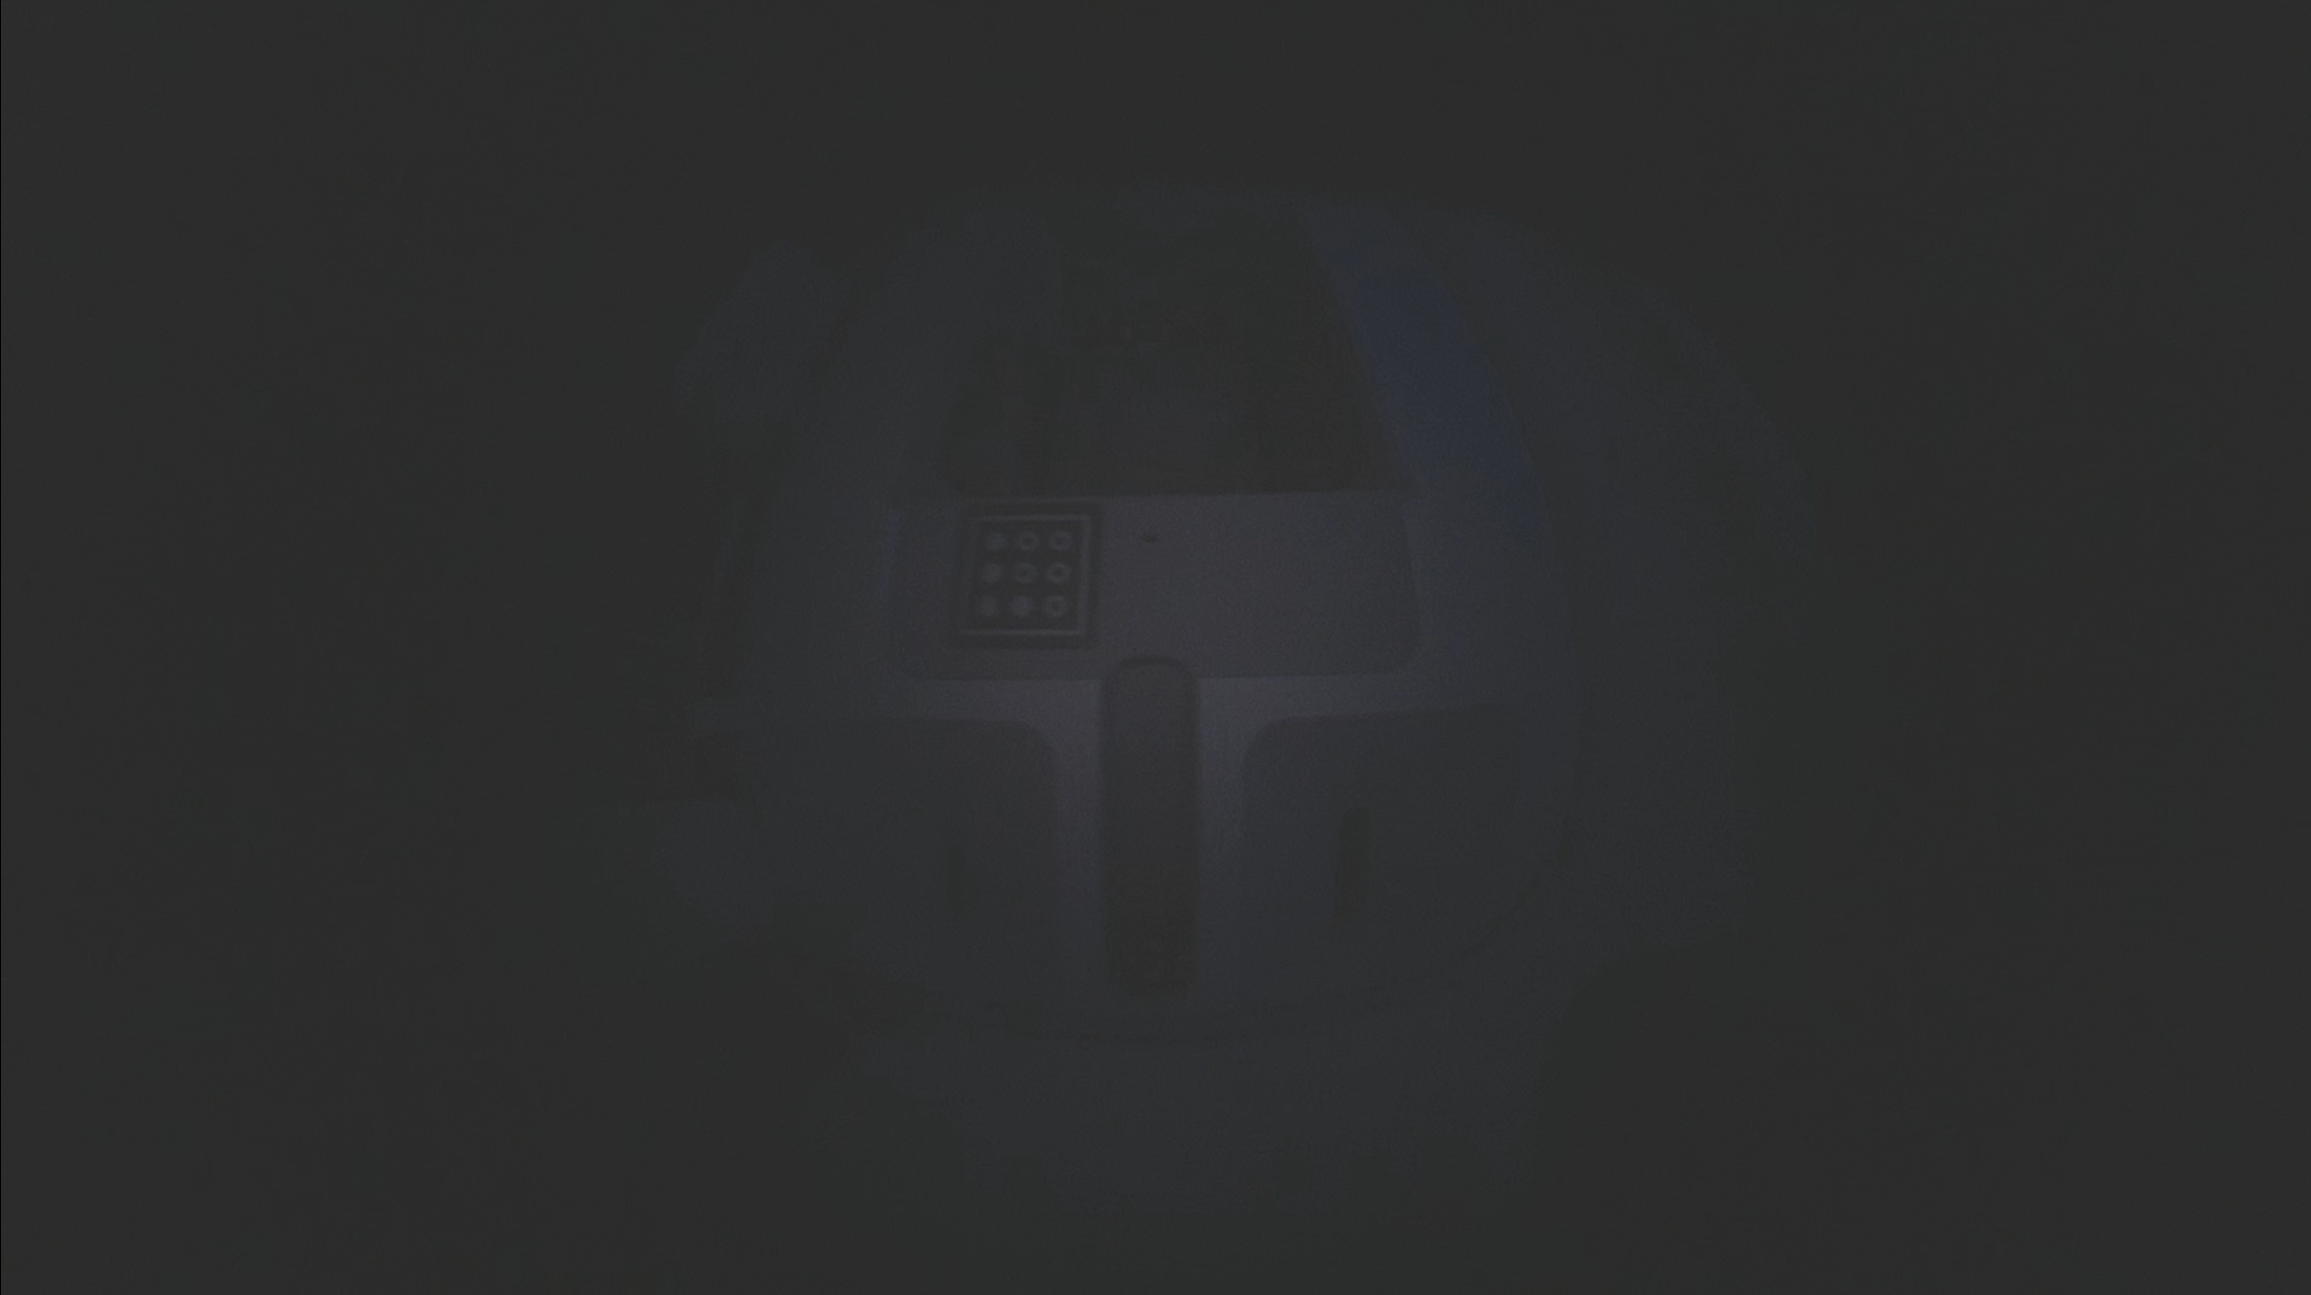
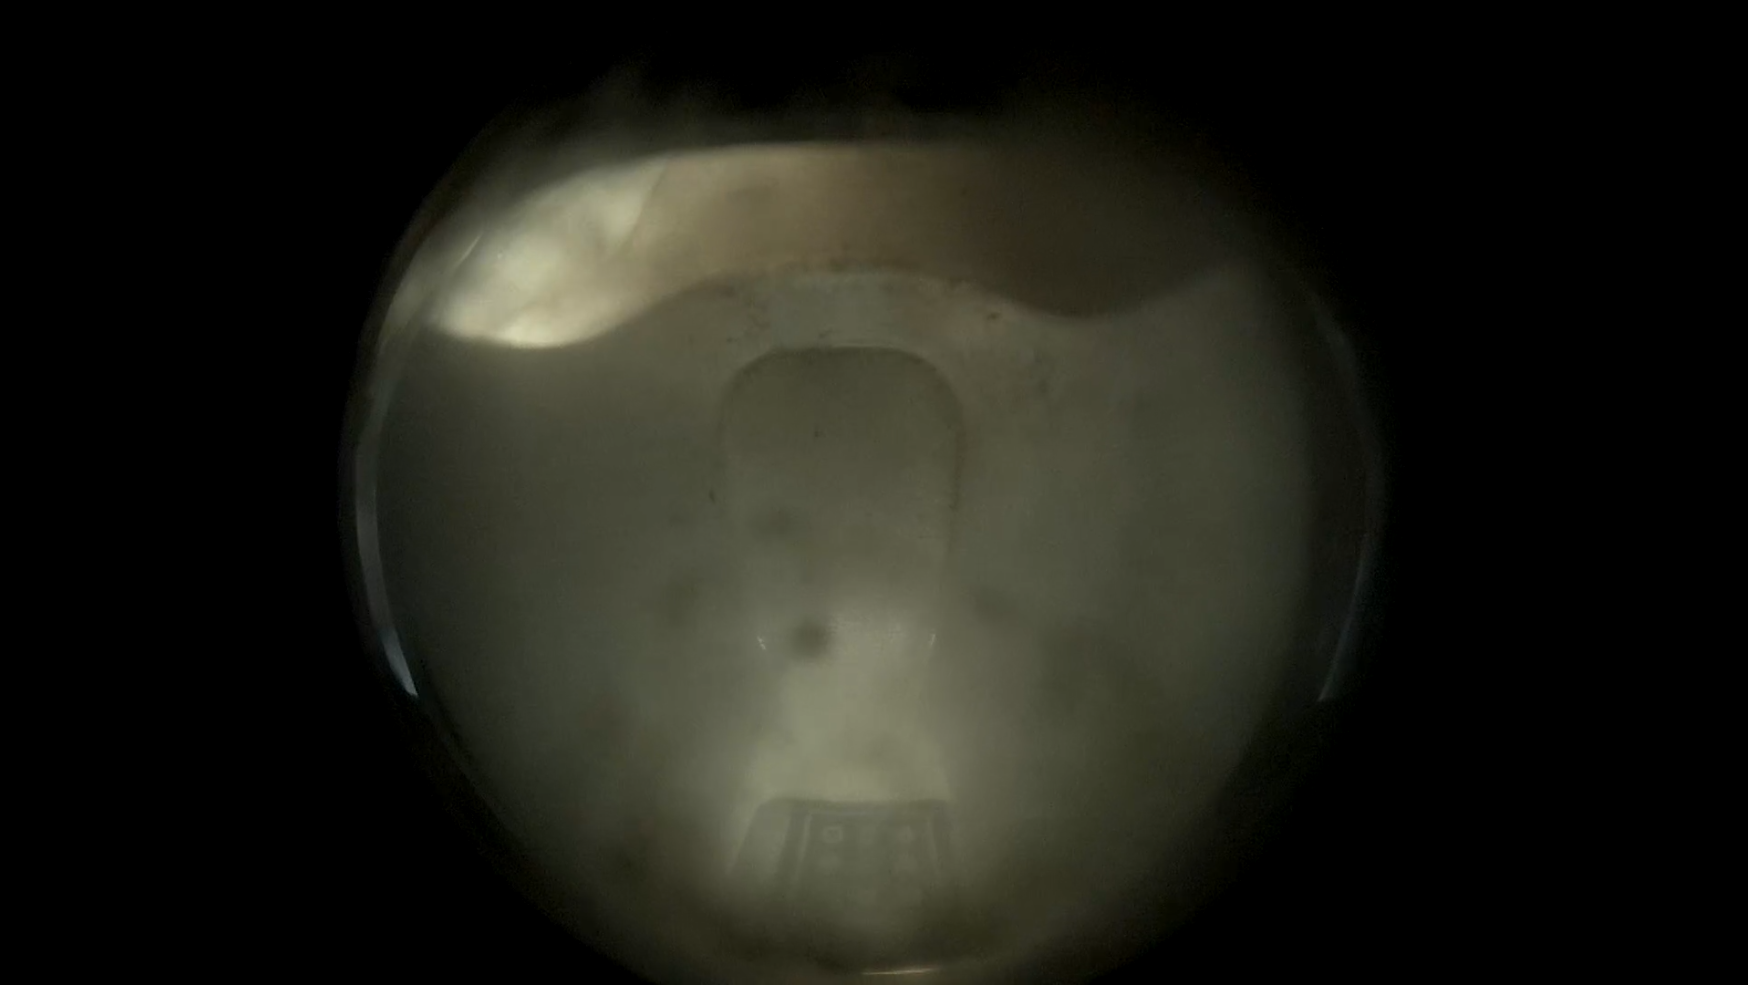
This has to be extremely obvious that the lens is significantly obscuring the view of the fiducials.
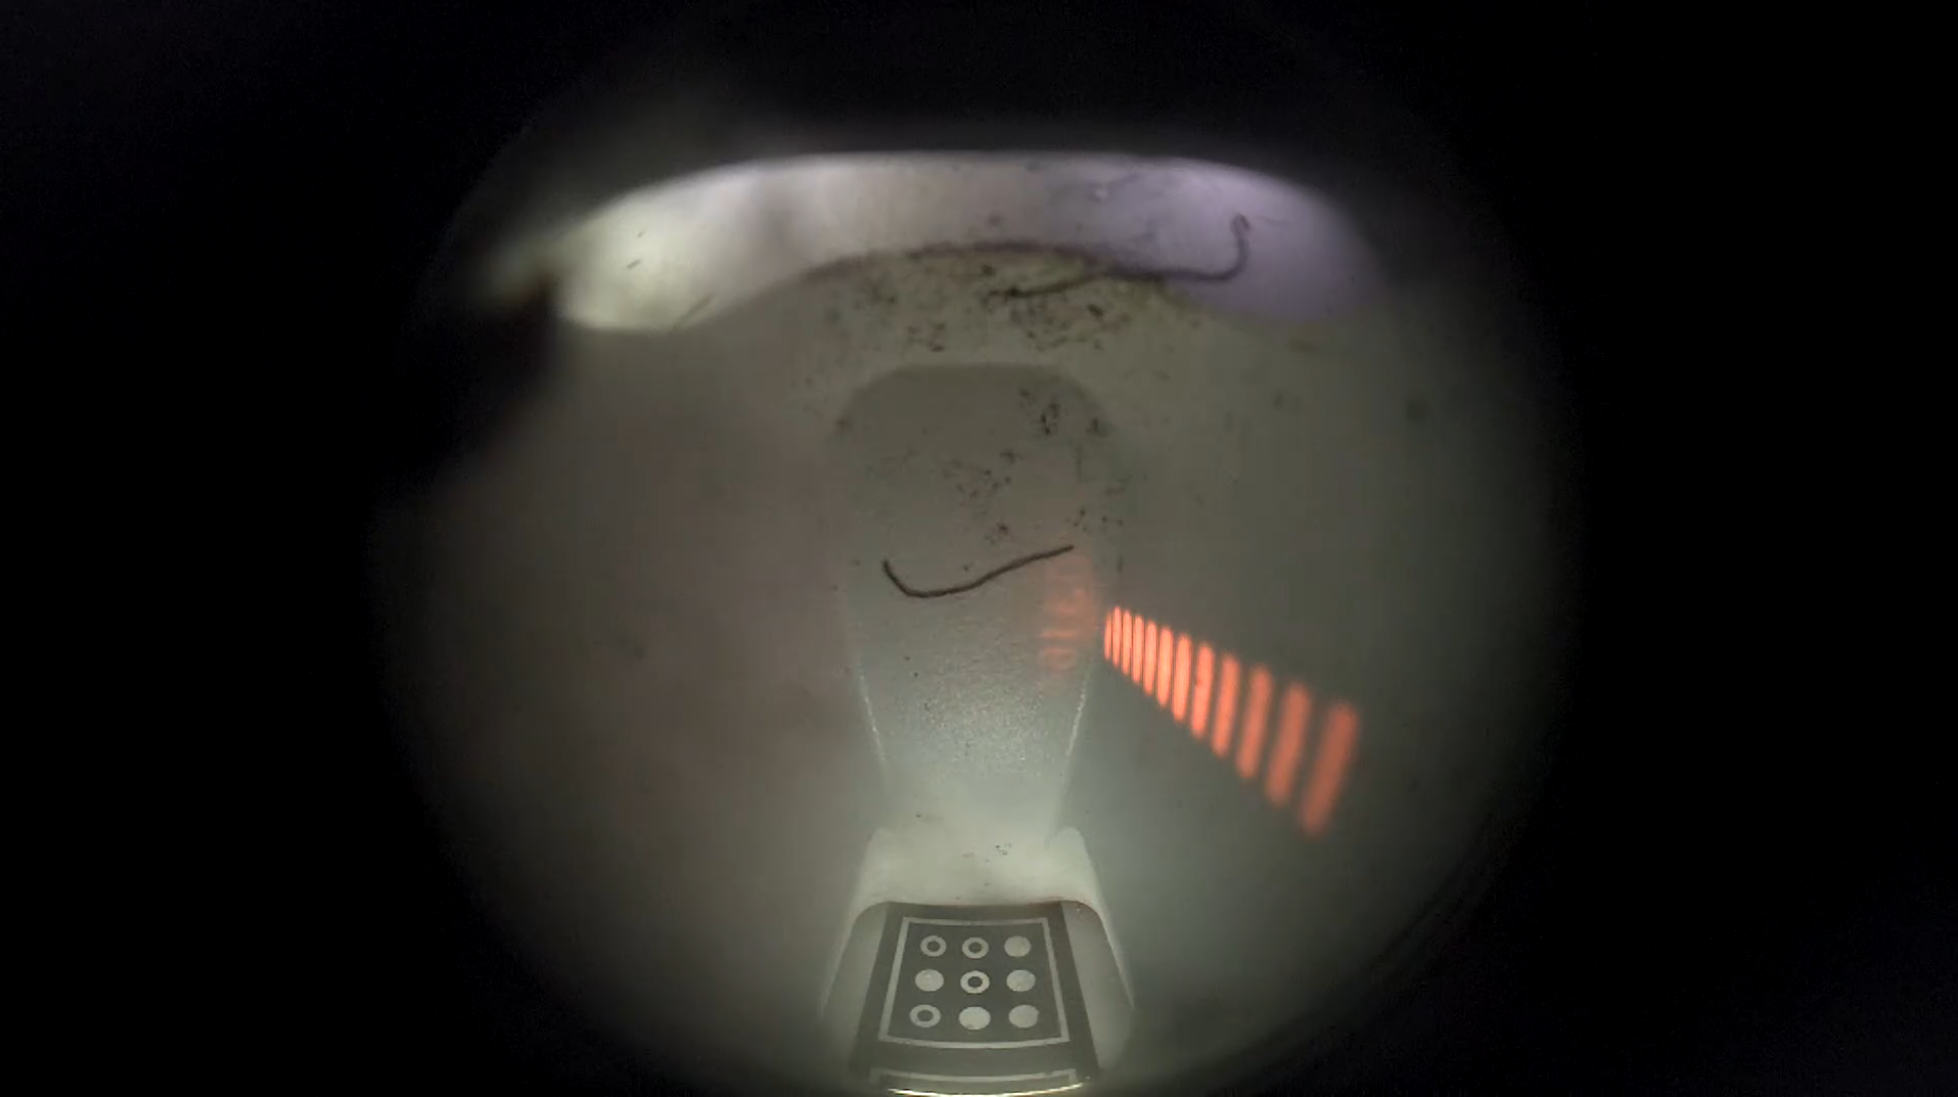
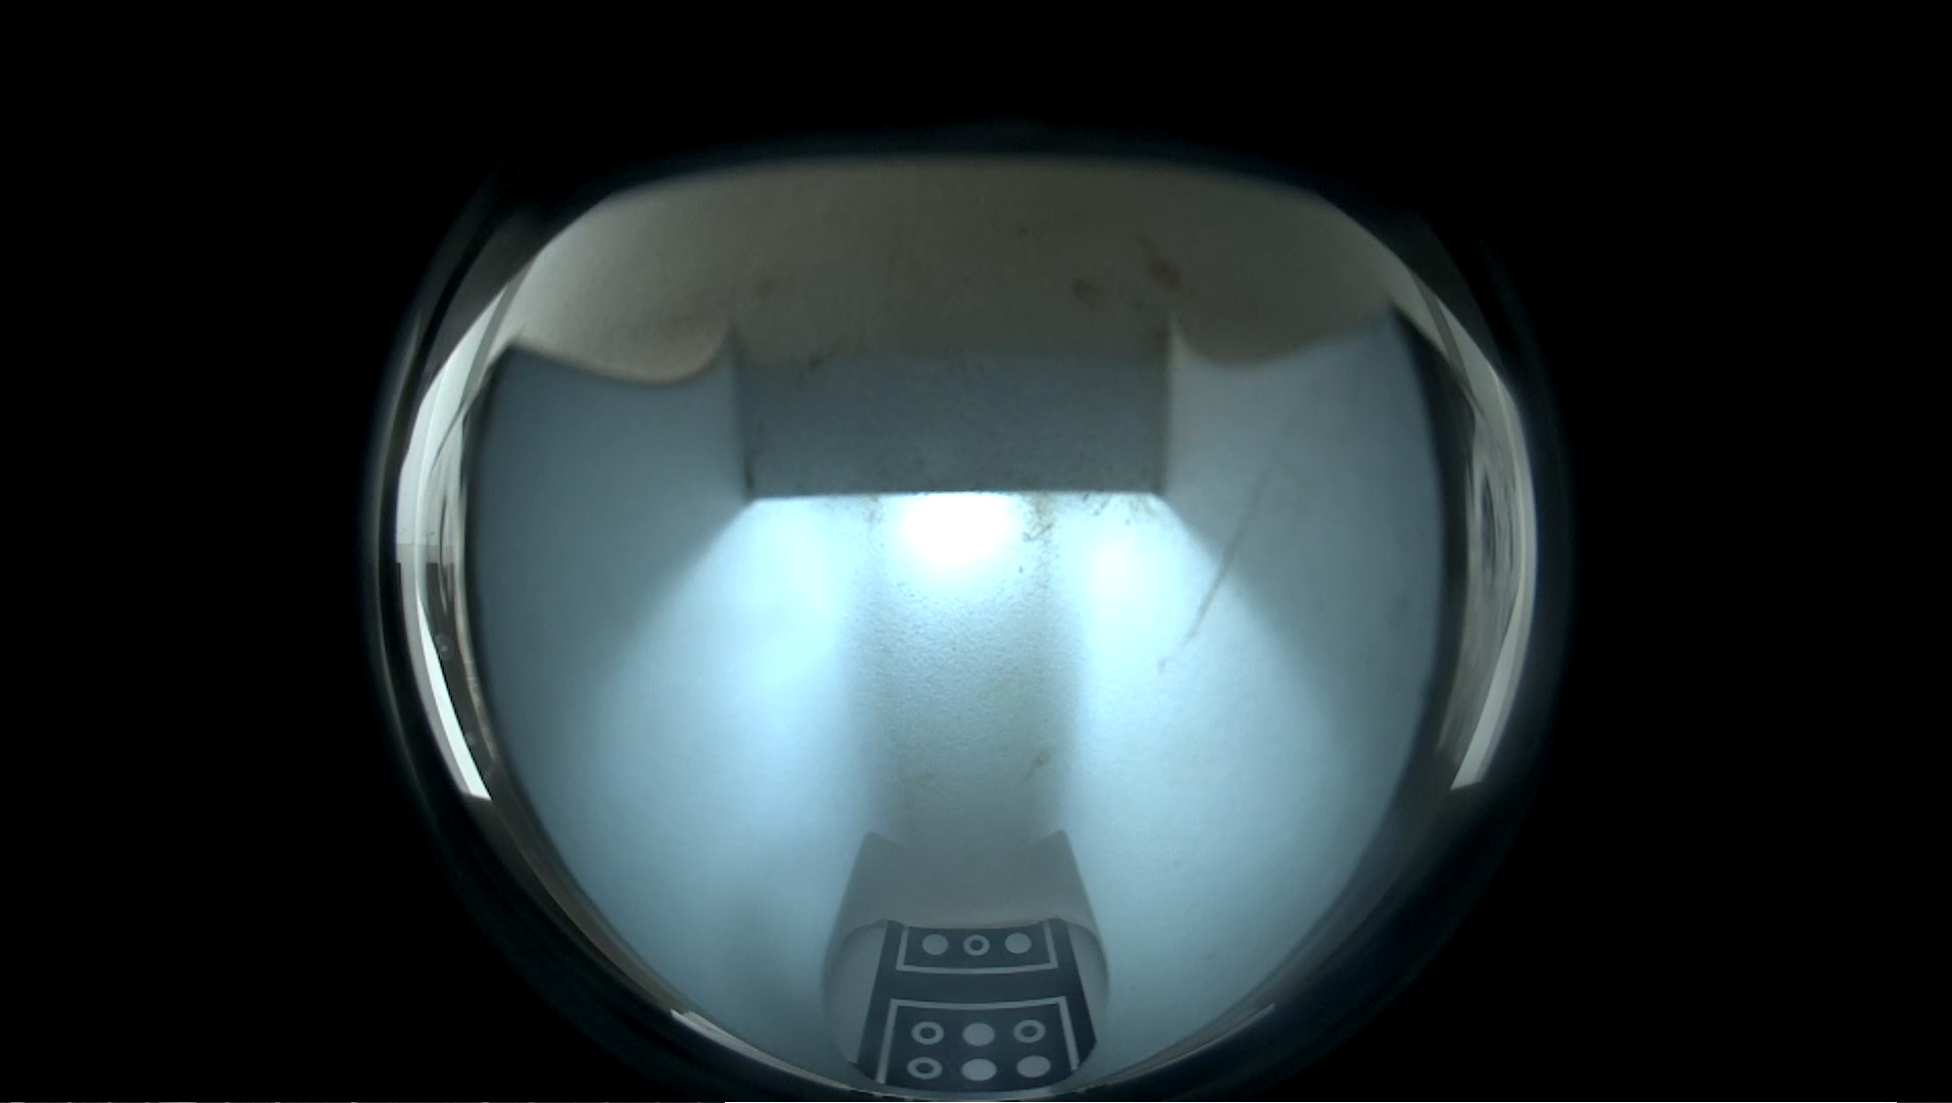
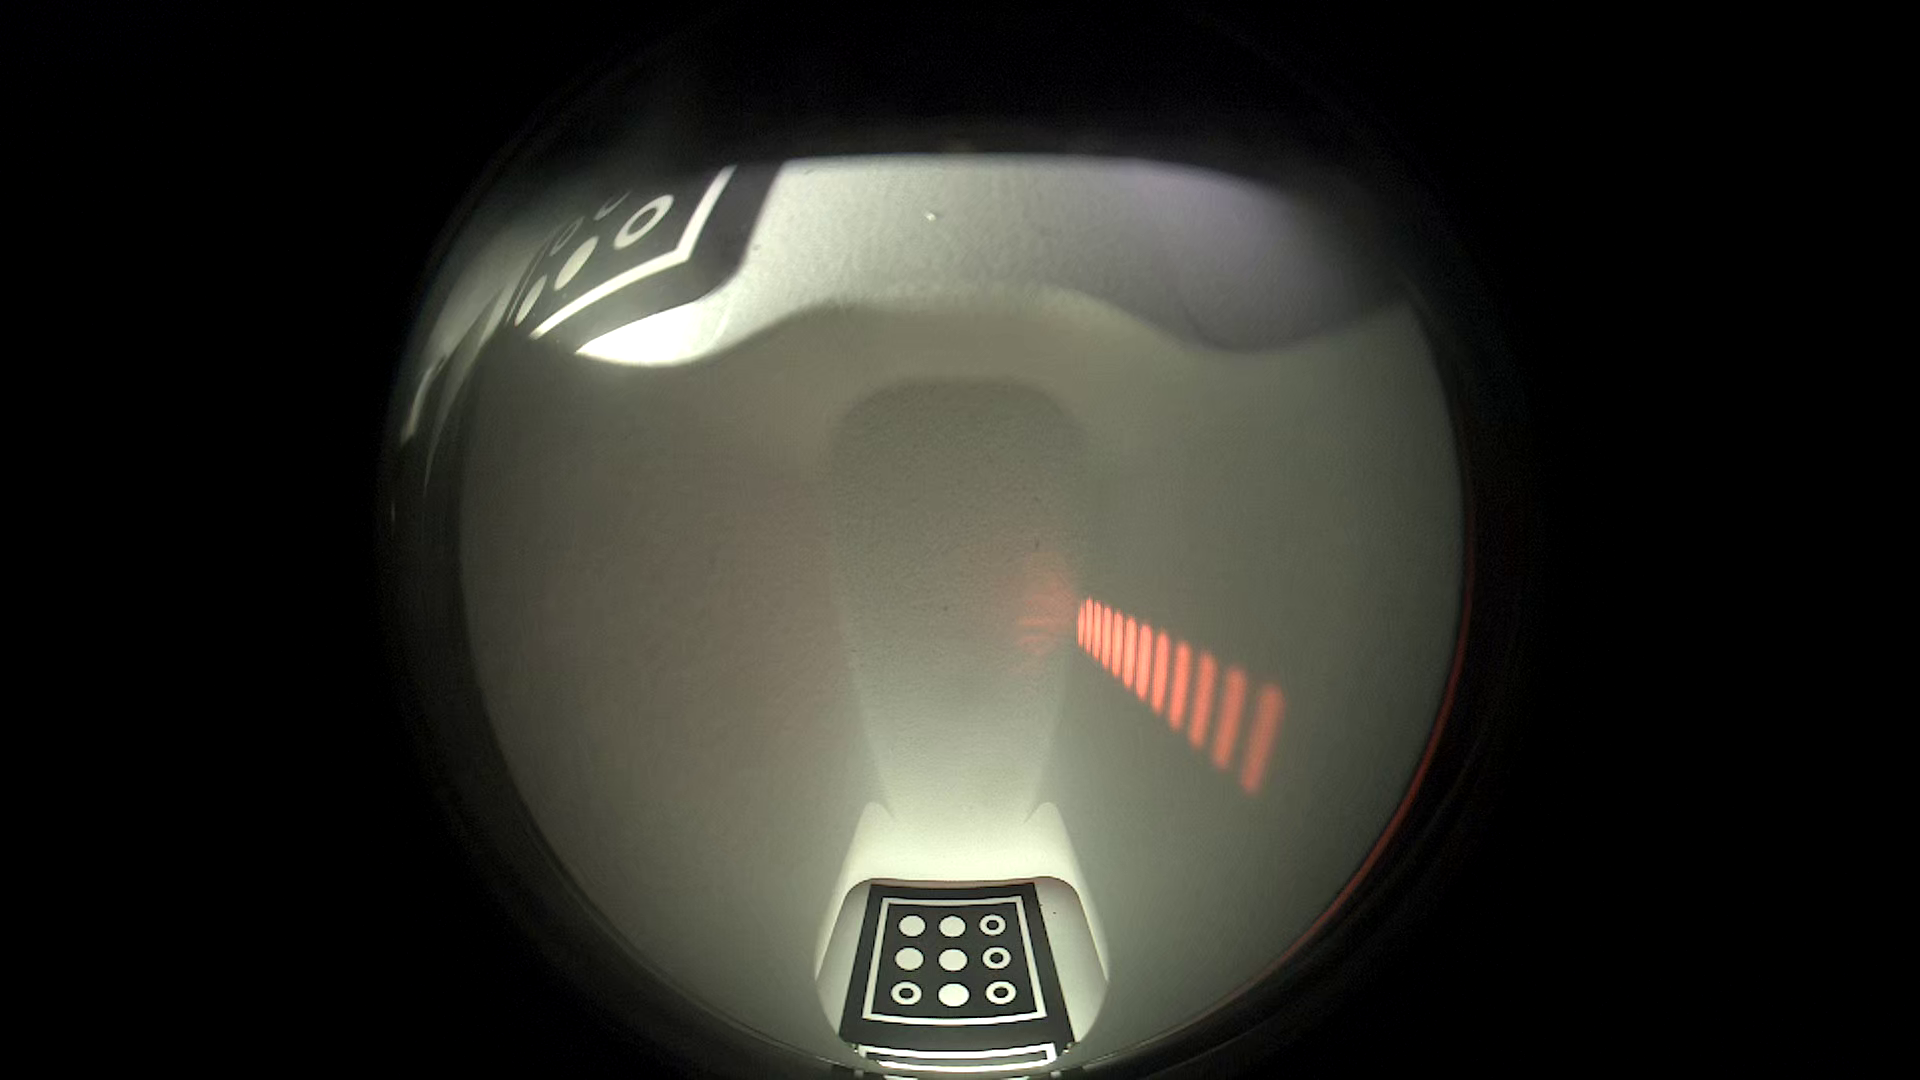
Carefully compare the dot pattern from the droid video to the image below.
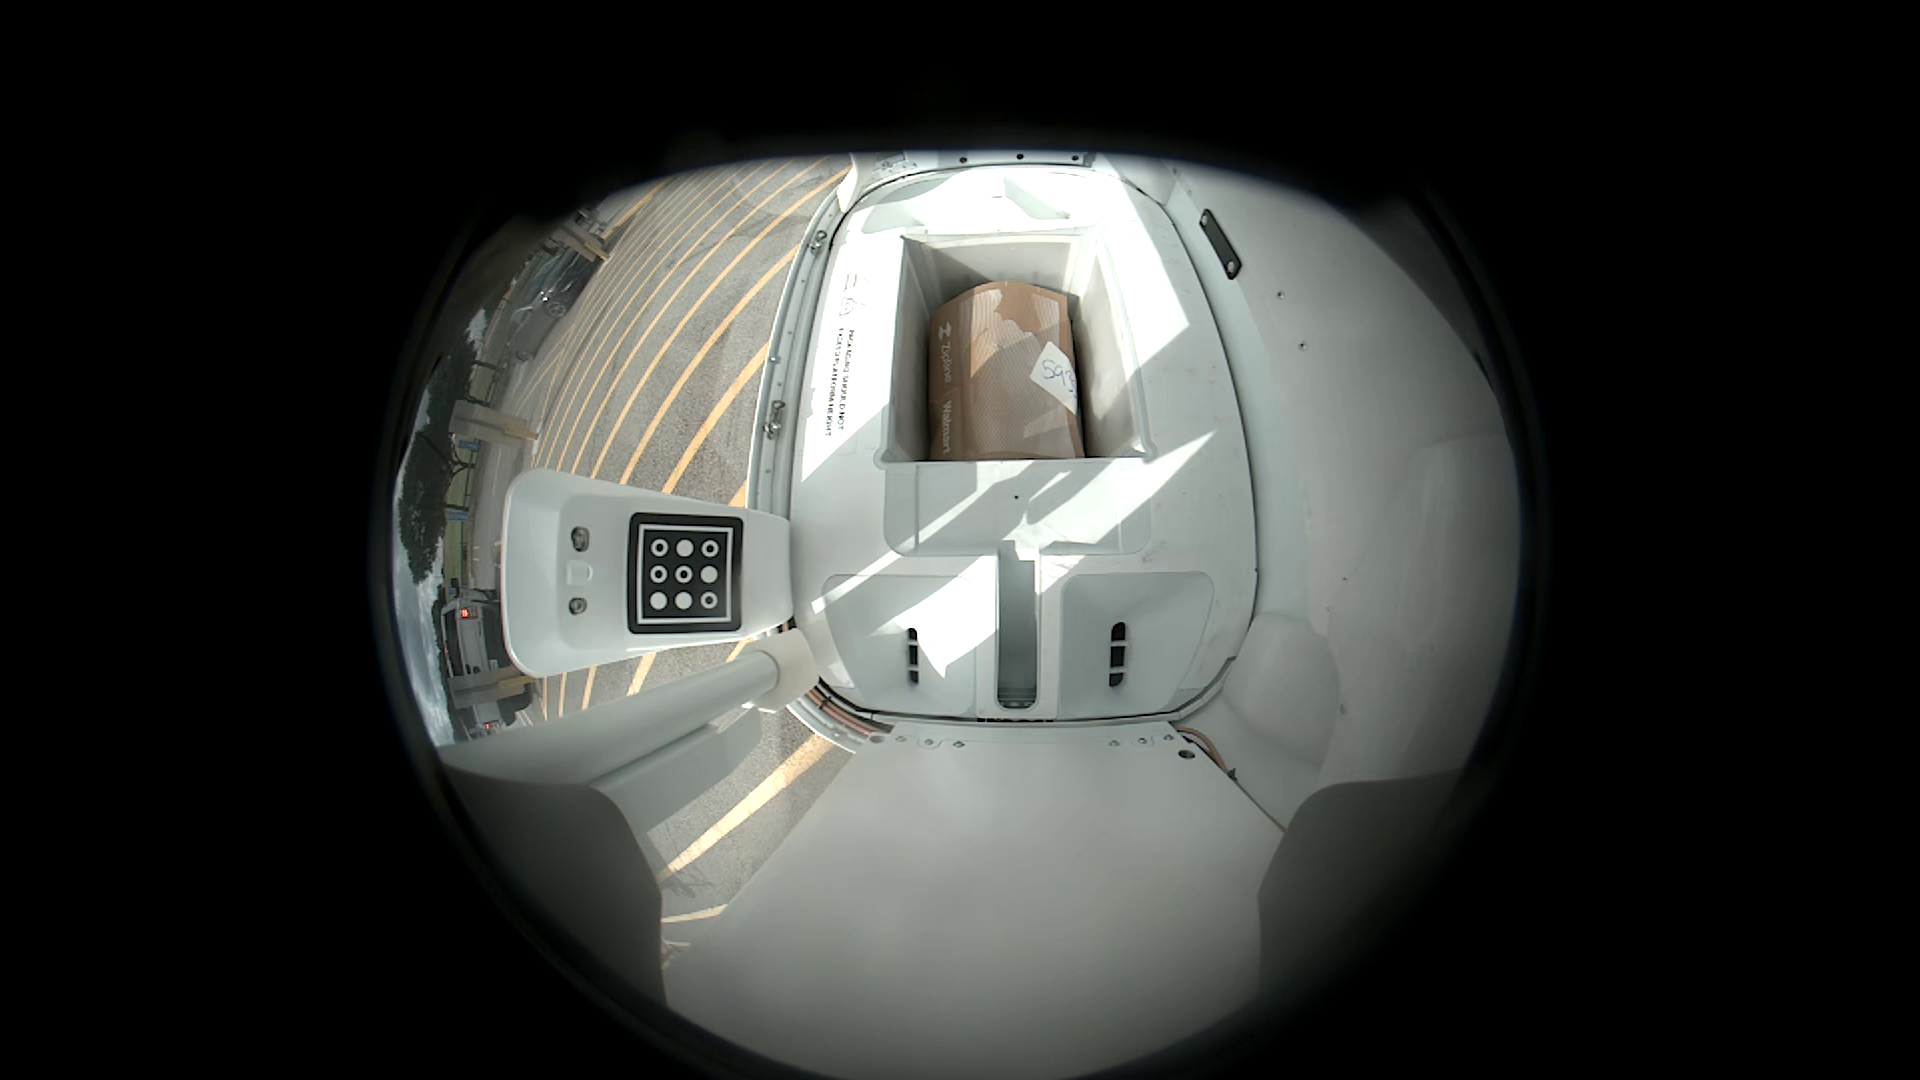
Review the video from the moment where the droid passes through the lid before it attempts the pickup. Confirm that the package is sitting properly on the magic carpet and that the magic carpet is not collapsed.
Upon completion of the work order, was an issue discovered and resolved?
See the Site Infrastructure Maintenance Manual (SIMM) for acceptable force ranges.
@David Carroll.Open the log plot template "Droid Navigation - online calibration checks for SE triaging team".
Use the
INVALID_CALIBRATION graph to check calibration validity.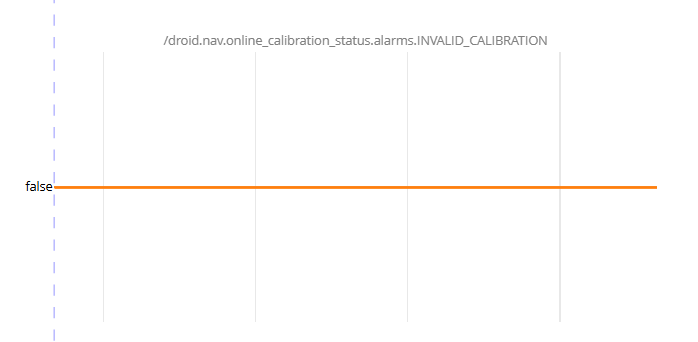
Healthy INVALID_CALIBRATION Graph
Resolution note
This plaintext block is ready to paste into the Resolution Note field on the ZERP issue you're working. The permalink below gives engineering review access to the full step-by-step timeline including any back-navigation; share it if the case needs a deeper look.
Permalink:
Session is too large to fit in a URL. Use Download session JSON to share the timeline out-of-band.
Did this guide help you get unblocked?
Open suggestions
There are no open suggestions.