

Basic Smart Cart Commands for Zip/Droid Troubleshooting
Below are a shortlist of commonly used aliases of command-line inputs when operating a smart cart with an aircraft and droid.
First, turn on all nodes: fw-zip-power -i enp3s0 all-on
Then find the command for the node you want to talk to from the sections below.
Troubleshooting Steps
Section titled “Troubleshooting Steps”graph TD
reference-page["<small><b>Step 1</b></small><br/>Action: This is a command reference page. See..."]
style reference-page fill:#dcfce7,stroke:#22c55e,color:#14532d Hover or focus a block to preview it. Select the block to keep the preview open.
Resolution note
This plaintext block is ready to paste into the Resolution Note field on the ZERP issue you're working. The permalink below gives engineering review access to the full step-by-step timeline including any back-navigation; share it if the case needs a deeper look.
Permalink:
Session is too large to fit in a URL. Use Download session JSON to share the timeline out-of-band.
Smart Cart
Section titled “Smart Cart”ping_devices- checks what nodes are reporting back from the ethernet interface- Zips should see compute_a, compute_b, distro_a, distro_b, and winch
- Droids should see droid_compute, droid_safety, thruster_main, thruster_fwd, thruster_aft
Interfacing with the Aircraft
Section titled “Interfacing with the Aircraft”- Turn ON/OFF
wake_zipshutdown_all(zip and droid)- other option:
shutdown_zip
- other option:
- Turn ON/OFF motor nodes
fw-zip-power -i enp3s0 all-onfw-zip-power -i enp3s0 avionics-only
- Access
ssh_compute_a/ssh_compute_b
Interfacing with the Droid
Section titled “Interfacing with the Droid”- Turn ON/OFF
- n/a - droid should auto-turn on
shutdown_droid
- Access
ssh_droid
EV2 Servo or Hover Node Pinging
Section titled “EV2 Servo or Hover Node Pinging”If you’re working on triaging either via visual inspection of the connection, you can use these targeted commands on a smart cart to see if the hover node is able to talk to the servo (ping).
Troubleshooting Steps
Section titled “Troubleshooting Steps”-
Distro A:
fw-update --ip fe80::20%enp3s0 --port 50051 read-config-proto -
Distro B:
fw-update --ip fe80::21%enp3s0 --port 50051 read-config-protoTail:
fw-update --ip fe80::22%enp3s0 --port 50051 read-config-proto- Servo Roll:
fw-update --ip fe80::22%enp3s0 --port 50057 read-config-proto - Servo Tilt:
fw-update --ip fe80::22%enp3s0 --port 50059 read-config-proto - Servo Tail Stbd Fwd:
fw-update --ip fe80::22%enp3s0 --port 50053 read-config-proto - Servo Tail Port Fwd:
fw-update --ip fe80::22%enp3s0 --port 50055 read-config-proto
- Servo Roll:
-
Winch:
fw-update --ip fe80::23%enp3s0 --port 50051 read-config-proto- Servo Tail Stbd Aft:
fw-update --ip fe80::23%enp3s0 --port 50053 read-config-proto - Servo Tail Port Aft:
fw-update --ip fe80::23%enp3s0 --port 50055 read-config-proto
- Servo Tail Stbd Aft:
-
Hover Port Fwd:
fw-update --ip fe80::30%enp3s0 --port 50051 read-config-proto- Servo Wing Port Fwd:
fw-update --ip fe80::30%enp3s0 --port 50053 read-config-proto
- Servo Wing Port Fwd:
-
Hover Port Aft:
fw-update --ip fe80::31%enp3s0 --port 50051 read-config-proto- Servo Wing Port Aft:
fw-update --ip fe80::31%enp3s0 --port 50053 read-config-proto
- Servo Wing Port Aft:
-
Hover Stbd Fwd:
fw-update --ip fe80::32%enp3s0 --port 50051 read-config-proto- Servo Wing Stbd Fwd:
fw-update --ip fe80::32%enp3s0 --port 50053 read-config-proto
- Servo Wing Stbd Fwd:
-
Hover Stbd Aft:
fw-update --ip fe80::33%enp3s0 --port 50051 read-config-proto- Servo Wing Stbd Aft:
fw-update --ip fe80::33%enp3s0 --port 50053 read-config-proto
- Servo Wing Stbd Aft:
-
Hover Mixed:
fw-update --ip fe80::24%enp3s0 --port 50051 read-config-proto
EV3 Servo or Hover Node Pinging
Section titled “EV3 Servo or Hover Node Pinging”There is no tail node. Only the Wings and Tails are Different from EV2
- Controlled by the winch
- Servo Tail Stbd Fwd:
fw-update --ip fe80::23%enp3s0 --port 50053 read-config-proto - Servo Tail Port Fwd:
fw-update --ip fe80::23%enp3s0 --port 50055 read-config-proto
- Servo Tail Stbd Fwd:
- Controlled by the aft motor nodes
- Servo Wing Stbd Fwd:
fw-update --ip fe80::33%enp3s0 --port 50053 read-config-proto - Servo Wing Port Fwd:
fw-update --ip fe80::31%enp3s0 --port 50053 read-config-proto
- Servo Wing Stbd Fwd:
Example of Servo or Node Ping Results
Section titled “Example of Servo or Node Ping Results”Successful pinging will start to read back what the node is.
This one was a servo_wing_port_fwd that reads back the pn and sn
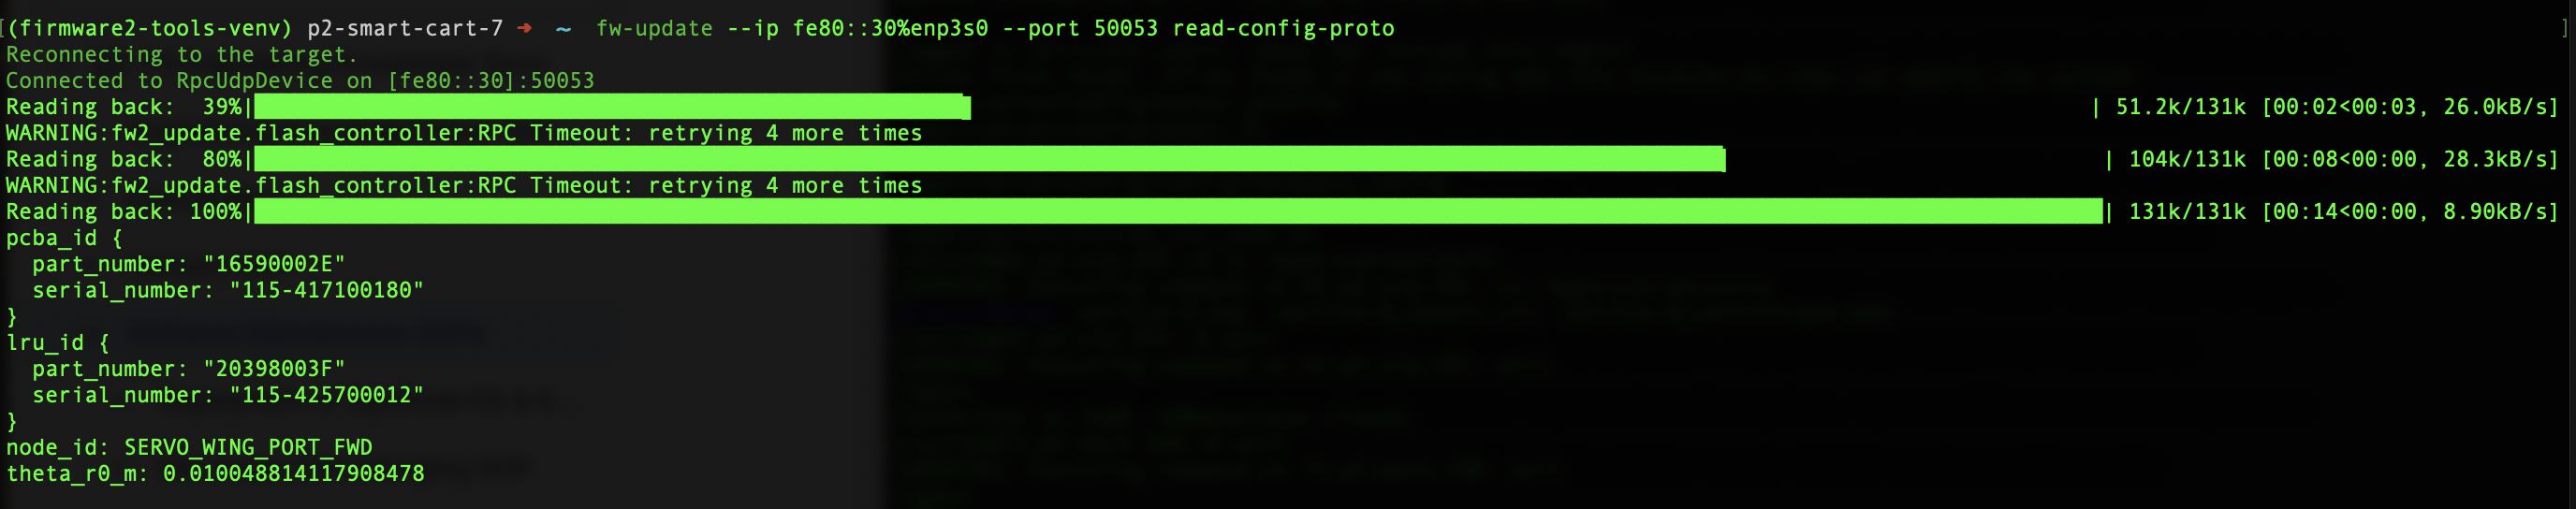
Unsuccessful pinging will cause it to continuously retry for 10 sec.
WARNING:fw2_chip.rpc_device:Connection timeout at t=2.0121400356292725, retrying... WARNING:fw2_chip.rpc_device:Connection timeout at t=3.5713353157043457, retrying... WARNING:fw2_chip.rpc_device:Connection timeout at t=5.191635847091675, retrying... WARNING:fw2_chip.rpc_device:Connection timeout at t=6.724374055862427, retrying... WARNING:fw2_chip.rpc_device:Connection timeout at t=8.281983375549316, retrying... WARNING:fw2_chip.rpc_device:Connection timeout at t=10.359217166900635, retrying...Example:
- I want to see if we can ping the servo_wing_stbd_aft
- Turn on all nodes
fw-zip-power -i enp3s0 all-on - Send:
fw-update --ip fe80::33%enp3s0 --port 50053 read-config-proto
Set the Zero Offset of Wings and Tails
Section titled “Set the Zero Offset of Wings and Tails”Position the control surface or tail such that it is flush with the rest of the wing or tail
- Controlled by the tail node
- Servo Tail Stbd Fwd:
fw-update --ip fe80::22%enp3s0 --port 50053 set-zero-offset - Servo Tail Port Fwd:
fw-update --ip fe80::22%enp3s0 --port 50055 set-zero-offset
- Servo Tail Stbd Fwd:
- Controlled by the forward motors
- Servo Wing Stbd Fwd:
fw-update --ip fe80::32%enp3s0 --port 50053 set-zero-offset - Servo Wing Port Fwd:
fw-update --ip fe80::30%enp3s0 --port 50053 set-zero-offset
- Servo Wing Stbd Fwd:
- Controlled by the winch
- Servo Tail Stbd Fwd:
fw-update --ip fe80::23%enp3s0 --port 50053 set-zero-offset - Servo Tail Port Fwd:
fw-update --ip fe80::23%enp3s0 --port 50055 set-zero-offset
- Servo Tail Stbd Fwd:
- Controlled by the aft motor nodes
- Servo Wing Stbd Fwd:
fw-update --ip fe80::33%enp3s0 --port 50053 set-zero-offset - Servo Wing Port Fwd:
fw-update --ip fe80::31%enp3s0 --port 50053 set-zero-offset
- Servo Wing Stbd Fwd:
Did this guide help you get unblocked?
Open suggestions
There are no open suggestions.
Open pull requests
There are no open pull requests.