

Hover Motor Missing Feedback
Applicable alarms (8)
Likely outcomes — click to expand
Based on 861,194 missions where this alarm fired in the last
90 days
(for STBD_FWD_MISSING_FEEDBACK) as of 2026-10-13
Grounding vs discrepancy (of 4,729 ZERP issues filed on these missions)
Top work orders
- EV2: Inspect Aircraft after Droid Left Behind (DLB) · MAINTENANCE_ACTION 232
- EV3: Inspect Aircraft after Droid Left Behind (DLB) · MAINTENANCE_ACTION 215
- Inspect Droid after Droid Left Behind (DLB) · MAINTENANCE_ACTION 184
- Reset Droid after DLB · REPAIR 118
- Troubleshoot Hover Motor Resistance on Aircraft · INSPECTION 78
Frequently replaced parts
| Part | P/N | Removals |
|---|---|---|
| SERVO, ASSY, UNIVERSAL, P2 | 20398 | 980 |
| CCW HOVER MOTOR ASSY, ZIP, P2 | 19607 | 803 |
| ASSY, SPOOL AND LINE, DOCKING FIN, AIRCRAFT, P2 | 48477 | 783 |
| PRE-PREG TAIL ASSY STBD(RH), ZIP, P2 | 21840 | 624 |
| PRE-PREG TAIL ASSY PORT(LH), DEPOP, ZIP, P2 | 31280 | 594 |
Aggregated from fleet operations and refreshed daily. Individual outcomes may vary by site and configuration.
Background
Section titled “Background”The GNC Zip Controller faulted a hover motor because expected feedback messages were missing. This usually points to a hardware communication issue, though firmware or compute issues are possible if comms checks do not explain the alarm.
Troubleshooting Steps
Section titled “Troubleshooting Steps”graph TD
check-rs485-comms{"<small><b>Step 1</b></small><br/>Question: Use the Baraza RS-485 errors template..."}
inspect-hover-flex["<small><b>Step 2</b></small><br/>Action: Inspect the relevant hover motor flex..."]
check-companion-alarms{"<small><b>Step 3</b></small><br/>Question: Were any of these Exec watchdog alarm..."}
follow-motor-control-guide["<small><b>Step 4</b></small><br/>Action: Follow the troubleshooting guide for ..."]
escalate-firmware-platform{{"<small><b>Step 5</b></small><br/>Escalation: Escalate to P2 Firmware Platform On C..."}}
check-rs485-comms -->|Yes, poor comms are present| inspect-hover-flex
check-rs485-comms -->|No, poor comms are not present| check-companion-alarms
check-companion-alarms -->|Yes, one or more listed ala...| follow-motor-control-guide
check-companion-alarms -->|No listed alarms were set| escalate-firmware-platform
style check-rs485-comms fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style inspect-hover-flex fill:#dcfce7,stroke:#22c55e,color:#14532d
style check-companion-alarms fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style follow-motor-control-guide fill:#dcfce7,stroke:#22c55e,color:#14532d
style escalate-firmware-platform fill:#fef3c7,stroke:#f59e0b,color:#78350f Hover or focus a block to preview it. Select the block to keep the preview open.
Template: zip-node-comms-rs-485-errors
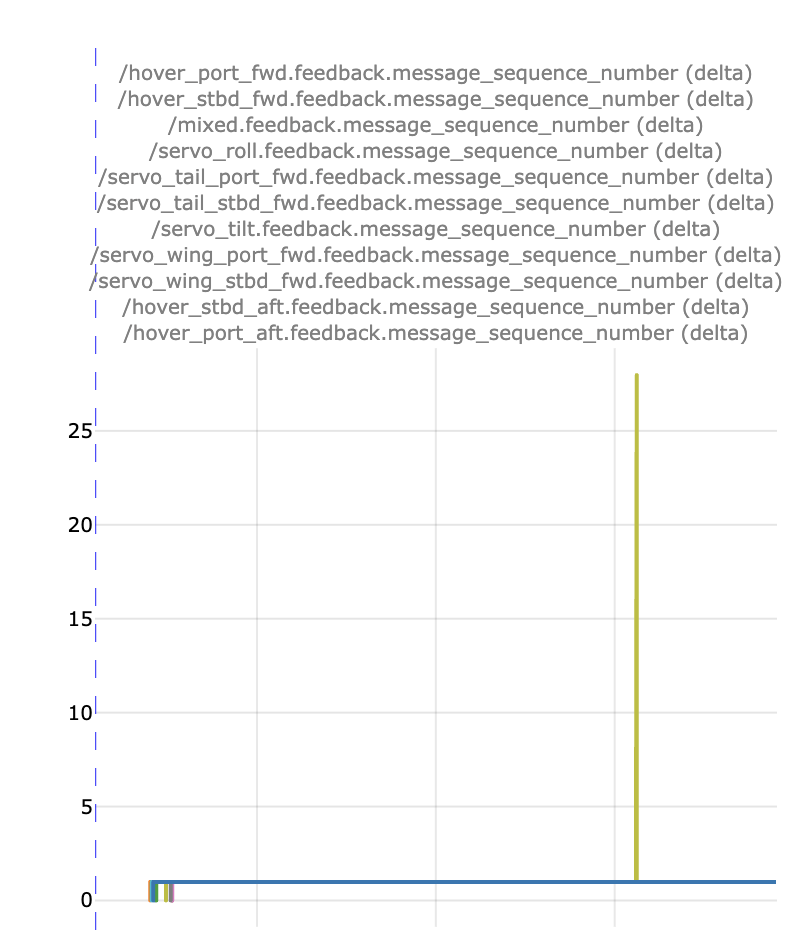
message_sequence_number(delta) should not exceed 1, except around a power cycle. The signal should never be negative unless the aircraft was power cycled; if that happens, use Show Alarms to identify the section of interest and zoom in on that section or adjust the y-axis. RX frame error should not exceed 10.Representative poor-comms example:
- MOTOR_CONTROL_FEEDBACK_HOVER_PORT_AFT_UNAVAILABLE
- MOTOR_CONTROL_FEEDBACK_HOVER_PORT_FWD_UNAVAILABLE
- MOTOR_CONTROL_FEEDBACK_HOVER_STBD_AFT_UNAVAILABLE
- MOTOR_CONTROL_FEEDBACK_HOVER_STBD_FWD_UNAVAILABLE
Resolution note
This plaintext block is ready to paste into the Resolution Note field on the ZERP issue you're working. The permalink below gives engineering review access to the full step-by-step timeline including any back-navigation; share it if the case needs a deeper look.
Permalink:
Session is too large to fit in a URL. Use Download session JSON to share the timeline out-of-band.
Did this guide help you get unblocked?
Open suggestions
There are no open suggestions.
Open pull requests
There are no open pull requests.