

LATCH_SERVICE_STATE_EMPTY
Applicable alarms (1)
Likely outcomes — click to expand
Based on 0 missions where this alarm fired in the last 90 days as of 2026-10-13
Aggregated from fleet operations and refreshed daily. Individual outcomes may vary by site and configuration.
Background
Section titled “Background”The cause is usually “a single jaw case.” Single jaw latching is when the Aircraft autonomously docks but only one of the latch jaws closes around the fin. The Dock does not accept this as a valid latched state, however there is no danger of the Aircraft falling out of the Dock. It simply means that it cannot retract automatically.
Another possible cause is failed communication between the Aircraft and the Dock. This is usually caused by a poor hardware connection somewhere between the Aircraft compute, distro, pins/sockets, and fin assembly.
Troubleshooting Steps
Section titled “Troubleshooting Steps”graph TD
confirm-that-this-is-a-single-jaw-case["<small><b>Step 1</b></small><br/>Action: Confirm that this is a single jaw cas..."]
is-single-jaw-case{"<small><b>Step 2</b></small><br/>Question: After the Aircraft docks control_mo..."}
single-jaw-case-follow-steps["<small><b>Step 3</b></small><br/>Action: This is a single jaw case. Use the **..."]
is-zip-detected-true-or-false{"<small><b>Step 4</b></small><br/>Question: Is zip_detected true or false?"}
follow-dock-not-communicating-with-aircr["<small><b>Step 5</b></small><br/>Action: Follow Dock Not Communicating with A..."]
is-hall-sensor-mv-between-1050-and-1900{"<small><b>Step 6</b></small><br/>Question: Is hall_sensor_mv between 1050 mV a..."}
dock-latch-hardware-swap-required["<small><b>Step 7</b></small><br/>Action: This requires a Dock latch hardware s..."]
double-check-latch-state-empty["<small><b>Step 8</b></small><br/>Action: 1. Double check that the latch state ..."]
confirm-that-this-is-a-single-jaw-case --> is-single-jaw-case
is-single-jaw-case -->|Yes| single-jaw-case-follow-steps
is-single-jaw-case -->|No| is-zip-detected-true-or-false
is-zip-detected-true-or-false -->|zip_detected = TRUE| is-hall-sensor-mv-between-1050-and-1900
is-zip-detected-true-or-false -->|zip_detected = FALSE| follow-dock-not-communicating-with-aircr
is-hall-sensor-mv-between-1050-and-1900 -->|Yes| dock-latch-hardware-swap-required
is-hall-sensor-mv-between-1050-and-1900 -->|No| double-check-latch-state-empty
style confirm-that-this-is-a-single-jaw-case fill:#dcfce7,stroke:#22c55e,color:#14532d
style is-single-jaw-case fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style single-jaw-case-follow-steps fill:#dcfce7,stroke:#22c55e,color:#14532d
style is-zip-detected-true-or-false fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style follow-dock-not-communicating-with-aircr fill:#dcfce7,stroke:#22c55e,color:#14532d
style is-hall-sensor-mv-between-1050-and-1900 fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style dock-latch-hardware-swap-required fill:#dcfce7,stroke:#22c55e,color:#14532d
style double-check-latch-state-empty fill:#dcfce7,stroke:#22c55e,color:#14532d Hover or focus a block to preview it. Select the block to keep the preview open.
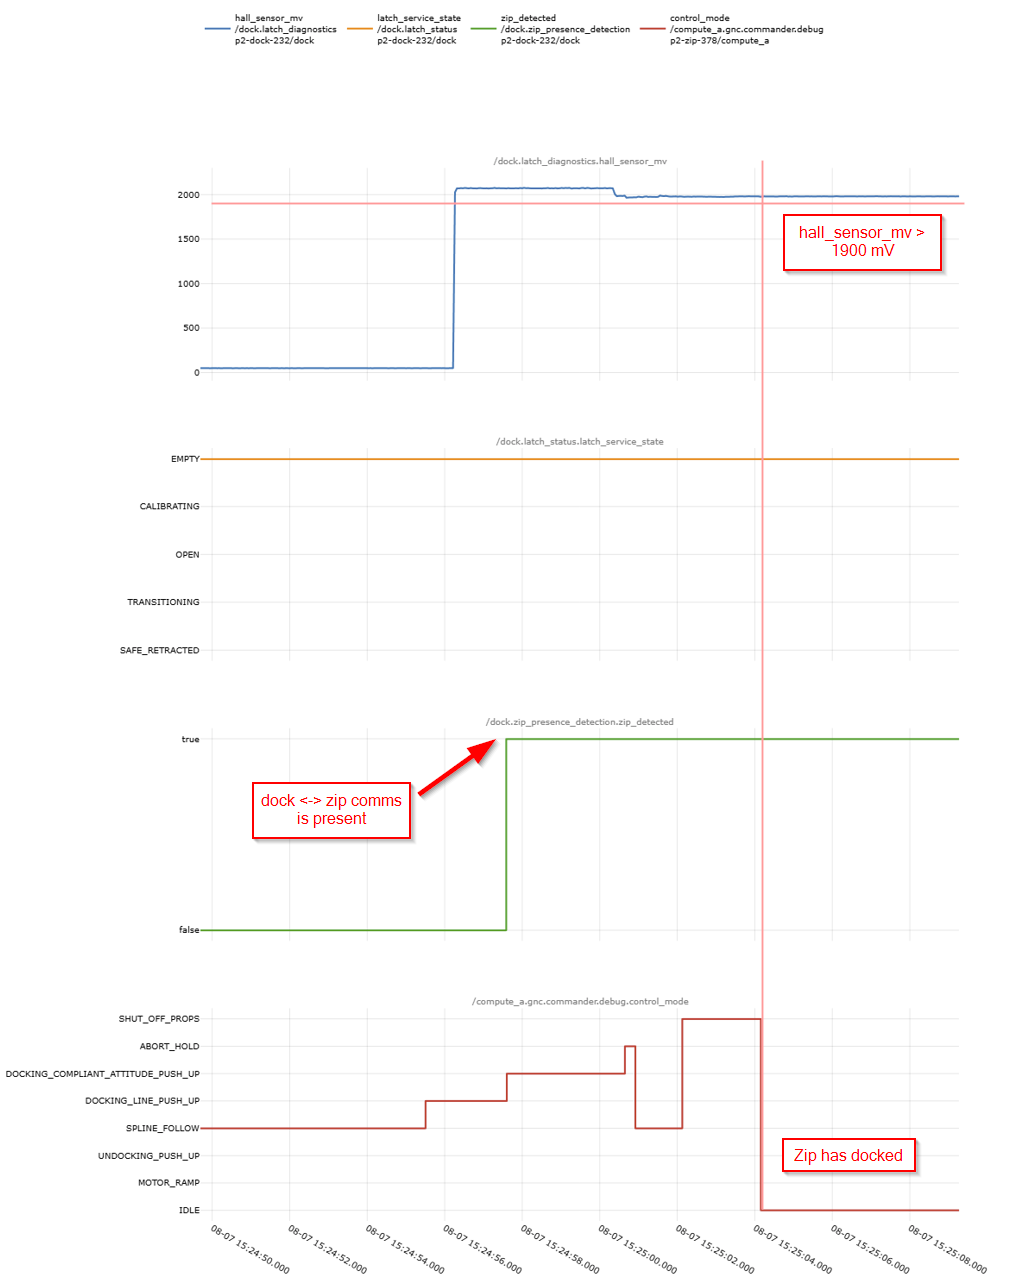
Use the baraza LogPlots template "Dock Latch EMPTY" on the applicable Mission ID.
control_mode is IDLE), is the hall_sensor_mv value >1900 mV AND is zip_detected set to TRUE?The log plot output should look like this:
zip_detected true or false?hall_sensor_mv between 1050 mV and 1900 mV?- Create a discrepancy against the dock and create an ISS ticket in the discrepancy.
- Remove the Aircraft from the Dock.
- As applicable, use a scissor lift or similar to get close to the Dock. If no scissor lift available, the tower will have to be lowered to remove the zip.
NOTE: It is recommended to have two operators supporting the Aircraft when removing it from the latch. - Send a Latch Open command. For steps, see Actuate Latch Commands to open the latch and release the Aircraft.
CAUTION: Ensure that the Aircraft is sufficiently supported prior to issuing this command.
- As applicable, use a scissor lift or similar to get close to the Dock. If no scissor lift available, the tower will have to be lowered to remove the zip.
hall_sensor_mv is < 1050 mV and zip_detected is true.2. Escalate to P2 Dock Embedded On Call.
Resolution note
This plaintext block is ready to paste into the Resolution Note field on the ZERP issue you're working. The permalink below gives engineering review access to the full step-by-step timeline including any back-navigation; share it if the case needs a deeper look.
Permalink:
Session is too large to fit in a URL. Use Download session JSON to share the timeline out-of-band.
Single Jaw Troubleshooting
Section titled “Single Jaw Troubleshooting”LATCH_SERVICE_STATE_EMPTY. Check the hall-effect sensor for a delayed retained state: if the hall-effect sensor is high while the latch state has been EMPTY for more than 8 seconds, note this in the Dock discrepancy before continuing.- As applicable, use a scissor lift or similar to get close to the Dock. If no scissor lift available, you may use a sufficiently long pole.
- Push on the Aircraft center body to close the other latch.
- In Fleet wrangler, check the Dock's Detailed Dock Status and that the latch service state reads
LATCH_SERVICE_STATE_RETAINED. This means that the Aircraft is fully in the latch. - Send a latch retract command. For steps, see Actuate Latch Commands.
- As applicable, use a scissor lift or similar to get close to the Dock. If no scissor lift available, the tower will have to be lowered to remove the zip.
NOTE: It is recommended to have two operators supporting the Aircraft when removing it from the latch. - Send a Latch Open command. For steps, see Actuate Latch Commands to open the latch and release the Aircraft.
CAUTION: Ensure that the Aircraft is sufficiently supported prior to issuing this command. - Re-insert the Aircraft into the Dock.
- In Fleet wrangler, check the Dock's Detailed Dock Status and confirm that the latch service state reads
LATCH_SERVICE_STATE_RETAINED. - Send a latch retract command. For steps, see Actuate Latch Commands.
Related Topics
Did this guide help you get unblocked?
Open suggestions
There are no open suggestions.
Open pull requests
There are no open pull requests.