

NIS_ABC_OVER_THRESHOLD
Applicable alarms (1)
Likely outcomes — click to expand
Based on 0 missions where this alarm fired in the last 90 days as of 2026-10-13
Aggregated from fleet operations and refreshed daily. Individual outcomes may vary by site and configuration.
Applicable to all hardware versions
Background
Section titled “Background”This alarm occurs when there is an extreme mismatch between a hover motor’s estimator model and its current sensor observations. The level of mismatch that triggers this alarm is strongly correlated with hardware damage.
Troubleshooting Steps
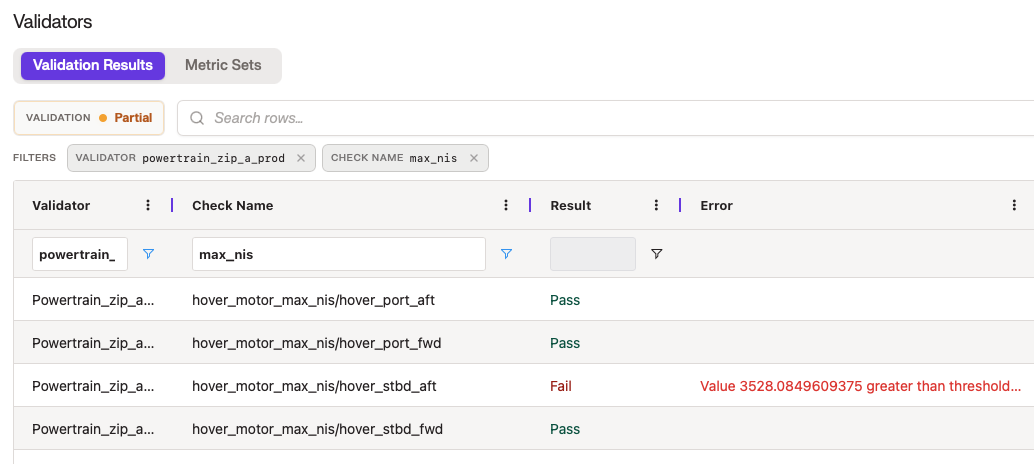
Section titled “Troubleshooting Steps”The powertrain_zip_a_production validators are run on spans, not missions, so you won’t see the data unless you have loaded the flight_id in Baraza rather than the mission_id.
graph TD
    verify-the-affected-hover-motor-s-by-v["<small><b>Step 1</b></small><br/>Action: Verify the affected hover motors by..."]
    i-found-the-failing-motor-s{"<small><b>Step 2</b></small><br/>Question: I found the failing motors"}
    replace-the-affected-hover-motor-s-an["<small><b>Step 3</b></small><br/>Action: Replace the affected hover motors a..."]
    is-the-alarm-persisting-after-motor-r{"<small><b>Step 4</b></small><br/>Question: Is the alarm persisting after motor r..."}
    escalate-to-p2-firmware-motors-on-call{{"<small><b>Step 5</b></small><br/>Escalation: Escalate to P2 Firmware Motors On Call."}}
    escalate-to-p2-firmware-motors-on-call-2{{"<small><b>Step 6</b></small><br/>Escalation: Escalate to P2 Firmware Motors On Call."}}
    follow-the-appropriate-troubleshootin["<small><b>Step 7</b></small><br/>Action: Follow the appropriate troubleshootin..."]
    the-aircraft-may-return-to-service["<small><b>Step 8</b></small><br/>Action: The Aircraft may return to service."]
    verify-the-affected-hover-motor-s-by-v --> i-found-the-failing-motor-s
    i-found-the-failing-motor-s -->|Continue to the next step.| replace-the-affected-hover-motor-s-an
    i-found-the-failing-motor-s -->|There is no validator data ...| escalate-to-p2-firmware-motors-on-call
    replace-the-affected-hover-motor-s-an --> is-the-alarm-persisting-after-motor-r
    is-the-alarm-persisting-after-motor-r -->|Yes| escalate-to-p2-firmware-motors-on-call-2
    is-the-alarm-persisting-after-motor-r -->|No, but there are other alarms| follow-the-appropriate-troubleshootin
    is-the-alarm-persisting-after-motor-r -->|No, there are no more alarms| the-aircraft-may-return-to-service
    style verify-the-affected-hover-motor-s-by-v fill:#dcfce7,stroke:#22c55e,color:#14532d
    style i-found-the-failing-motor-s fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
    style replace-the-affected-hover-motor-s-an fill:#dcfce7,stroke:#22c55e,color:#14532d
    style is-the-alarm-persisting-after-motor-r fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
    style escalate-to-p2-firmware-motors-on-call fill:#fef3c7,stroke:#f59e0b,color:#78350f
    style escalate-to-p2-firmware-motors-on-call-2 fill:#fef3c7,stroke:#f59e0b,color:#78350f
    style follow-the-appropriate-troubleshootin fill:#dcfce7,stroke:#22c55e,color:#14532d
    style the-aircraft-may-return-to-service fill:#dcfce7,stroke:#22c55e,color:#14532d
Hover or focus a block to preview it. Select the block to keep the preview open.
hover_motor_max_nis check in the powertrain_zip_a_production validator.WORK ORDER TEMPLATE: Use Work Order Template #90 - Replace Hover Motor on Aircraft.
Resolution note
This plaintext block is ready to paste into the Resolution Note field on the ZERP issue you're working. The permalink below gives engineering review access to the full step-by-step timeline including any back-navigation; share it if the case needs a deeper look.
Permalink:
Session is too large to fit in a URL. Use Download session JSON to share the timeline out-of-band.
Did this guide help you get unblocked?
Open suggestions
There are no open suggestions.
Open pull requests
There are no open pull requests.