

0x00100194 ZIP_EXECUTIVE_V4_DROID_PARTIALLY_CONSTRAINED
Applicable alarms (3)
Likely outcomes — click to expand
Based on 0 missions where this alarm fired in the last
90 days
(for 0x00100194) as of 2026-10-13
Aggregated from fleet operations and refreshed daily. Individual outcomes may vary by site and configuration.
Applicable to all hardware versions
Background
Section titled “Background”Zip Executive does not report which partial-constraint signal caused this error. Use the node in the error report to choose the compute-specific Baraza template, then follow the matching signal path.
Troubleshooting Steps
Section titled “Troubleshooting Steps”graph TD
is-the-error-from-compute-a-or-compute-b{"<small><b>Step 1</b></small><br/>Question: Is the error from compute A or comput..."}
open-the-compute-a-debug-template["<small><b>Step 2</b></small><br/>Action: Open the debug_droid_partially_const..."]
which-compute-a-signal-is-set{"<small><b>Step 3</b></small><br/>Question: At the time of mission failure, what ..."}
open-the-compute-b-debug-template["<small><b>Step 4</b></small><br/>Action: Open the debug_droid_partially_const..."]
which-compute-b-signal-is-set{"<small><b>Step 5</b></small><br/>Question: At the time of mission failure, what ..."}
winch-latch-status-look-at-this-templat["<small><b>Step 6</b></small><br/>Action: Look at this template : https://bara..."]
does-the-plot-for-distro-b-metrics-netw{"<small><b>Step 7</b></small><br/>Question: Does the plot for *distro_b.metrics.n..."}
the-winch-flex-is-damaged-create-a-work["<small><b>Step 8</b></small><br/>Action: The winch flex is damaged. Create a w..."]
escalate-to-p2-avionics-hardware-on-cal{{"<small><b>Step 9</b></small><br/>Escalation: Escalate to P2 Avionics Hardware On C..."}}
wired-comms-reseat-droid("<small><b>Step 10</b></small><br/>Reference: Follow Reseat Droid/procedures/res...")
if-reseat-droid-does-not-work["<small><b>Step 11</b></small><br/>Action: If reseating the Droid does not resol..."]
lock-mechanism-escalate-to-p2-firmware{{"<small><b>Step 12</b></small><br/>Escalation: Escalate to P2 Firmware Platform On C..."}}
is-the-error-from-compute-a-or-compute-b -->|Compute A| open-the-compute-a-debug-template
is-the-error-from-compute-a-or-compute-b -->|Compute B| open-the-compute-b-debug-template
open-the-compute-a-debug-template --> which-compute-a-signal-is-set
which-compute-a-signal-is-set -->|is_latched is false| winch-latch-status-look-at-this-templat
which-compute-a-signal-is-set -->|lock_mech_state is not L...| lock-mechanism-escalate-to-p2-firmware
open-the-compute-b-debug-template --> which-compute-b-signal-is-set
which-compute-b-signal-is-set -->|Heartbeat connected is false| wired-comms-reseat-droid
which-compute-b-signal-is-set -->|lock_mech_state is not L...| lock-mechanism-escalate-to-p2-firmware
winch-latch-status-look-at-this-templat --> does-the-plot-for-distro-b-metrics-netw
does-the-plot-for-distro-b-metrics-netw -->|Yes| the-winch-flex-is-damaged-create-a-work
does-the-plot-for-distro-b-metrics-netw -->|No| escalate-to-p2-avionics-hardware-on-cal
wired-comms-reseat-droid --> if-reseat-droid-does-not-work
style is-the-error-from-compute-a-or-compute-b fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style open-the-compute-a-debug-template fill:#dcfce7,stroke:#22c55e,color:#14532d
style which-compute-a-signal-is-set fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style open-the-compute-b-debug-template fill:#dcfce7,stroke:#22c55e,color:#14532d
style which-compute-b-signal-is-set fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style winch-latch-status-look-at-this-templat fill:#dcfce7,stroke:#22c55e,color:#14532d
style does-the-plot-for-distro-b-metrics-netw fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style the-winch-flex-is-damaged-create-a-work fill:#dcfce7,stroke:#22c55e,color:#14532d
style escalate-to-p2-avionics-hardware-on-cal fill:#fef3c7,stroke:#f59e0b,color:#78350f
style wired-comms-reseat-droid fill:#f3e8ff,stroke:#a855f7,color:#581c87
style if-reseat-droid-does-not-work fill:#dcfce7,stroke:#22c55e,color:#14532d
style lock-mechanism-escalate-to-p2-firmware fill:#fef3c7,stroke:#f59e0b,color:#78350f Hover or focus a block to preview it. Select the block to keep the preview open.
Check the node in the error report to find out.
is_latched and lock_mech_state?Use the mission status in the first plot to find the mission failure time.
lock_mech_state and the heartbeat connected signal?Use the mission status in the first plot to find the mission failure time.
>5 (that is, the difference in toggle count at the end of flight vs start is >5)?Example:
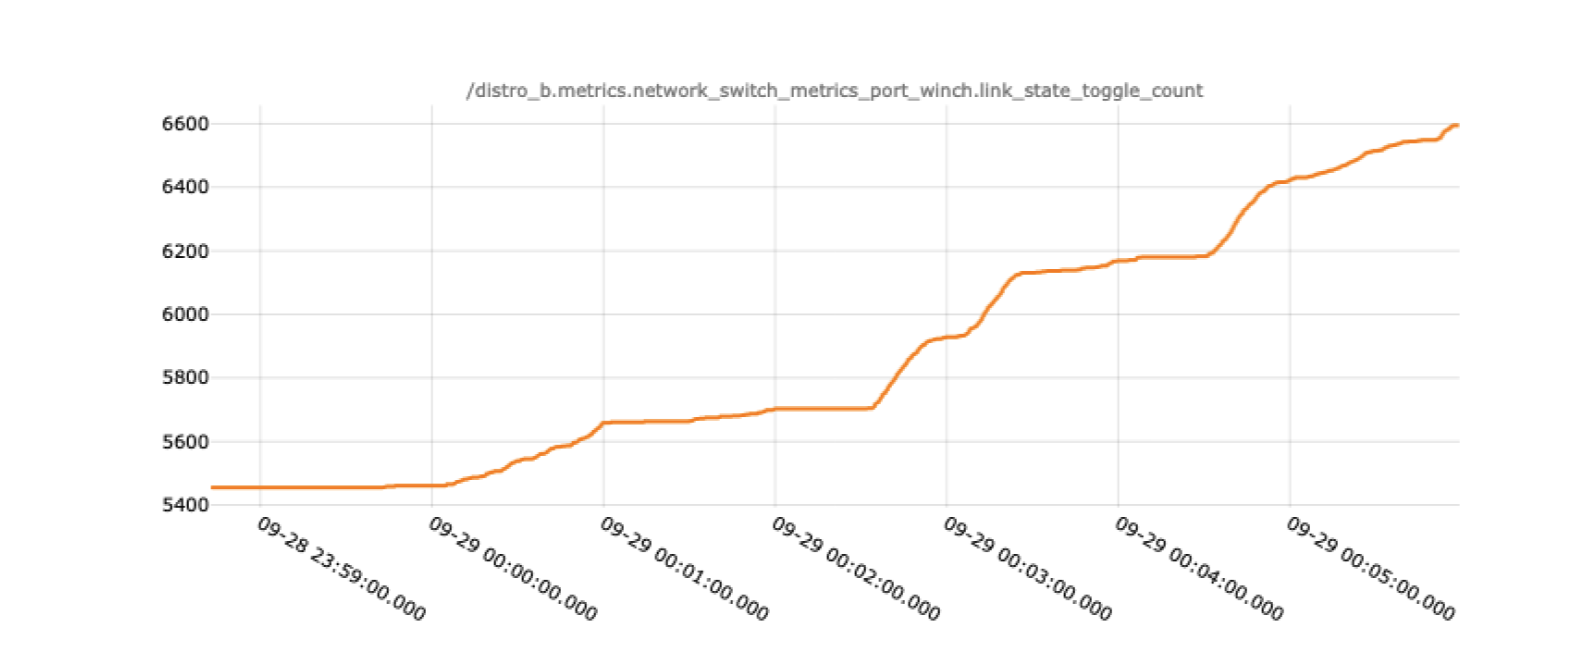
Create a work order to replace winch flex harness.
Resolution note
This plaintext block is ready to paste into the Resolution Note field on the ZERP issue you're working. The permalink below gives engineering review access to the full step-by-step timeline including any back-navigation; share it if the case needs a deeper look.
Permalink:
Session is too large to fit in a URL. Use Download session JSON to share the timeline out-of-band.
Did this guide help you get unblocked?
Open suggestions
There are no open suggestions.
Open pull requests
There are no open pull requests.