

Motor Startup Failure
Background
Section titled “Background”Healthy propulsion motors occasionally fail to start up. These are probabilistic firmware failures not necessarily indicative of hardware damage. A motor may have to start up many times in a single mission. A validator tracks the time it takes for it to startup in each instance. If it never starts up, that validator’s metric would read -1 for that instance.
Troubleshooting Steps
Section titled “Troubleshooting Steps”graph TD
check-startup-validator{"<small><b>Step 1</b></small><br/>Question: Check validator results for this flig..."}
return-to-service-startup["<small><b>Step 2</b></small><br/>Action: This is a low-occurrence probabilisti..."]
escalate-firmware-motors{{"<small><b>Step 3</b></small><br/>Escalation: Escalate to P2 Firmware Motors On Cal..."}}
check-startup-validator -->|Yes, the value is -1| return-to-service-startup
check-startup-validator -->|No, the value is not -1| escalate-firmware-motors
check-startup-validator -->|The startup metric is missi...| escalate-firmware-motors
style check-startup-validator fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style return-to-service-startup fill:#dcfce7,stroke:#22c55e,color:#14532d
style escalate-firmware-motors fill:#fef3c7,stroke:#f59e0b,color:#78350f Hover or focus a block to preview it. Select the block to keep the preview open.
In the validator results, find the startup metrics for the affected hover motor:
propulsion_motor_startup/{motor}_torque_control_startup_time_s_occurrence_{n}, where {motor} is hover_port_aft, hover_stbd_aft, hover_port_fwd, or hover_stbd_fwd. There may be multiple occurrences. Check only the last occurrence—the metric with the highest numeric value of {n}.The validator is in the Zip A, Firmware_zip_a_ev2_experimental space.
Does the validator value read
-1?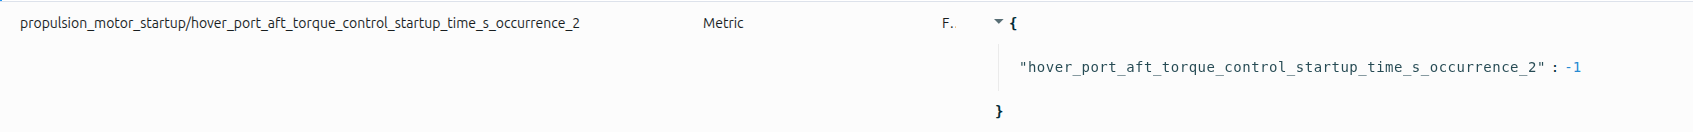
Resolution note
This plaintext block is ready to paste into the Resolution Note field on the ZERP issue you're working. The permalink below gives engineering review access to the full step-by-step timeline including any back-navigation; share it if the case needs a deeper look.
Permalink:
Session is too large to fit in a URL. Use Download session JSON to share the timeline out-of-band.
Did this guide help you get unblocked?
Open suggestions
There are no open suggestions.
Open pull requests
There are no open pull requests.