

Validator: Ethernet_health_signal_strength/distro*
Applicable alarms (2)
Likely outcomes — click to expand
Based on 0 missions where this alarm fired in the last
90 days
(for Ethernet_health_signal_strength/distro_b_port_droid_sqi_a_wc) as of 2026-10-13
Aggregated from fleet operations and refreshed daily. Individual outcomes may vary by site and configuration.
Use this guide to troubleshoot the following shakedown validators:
- Ethernet_health_signal_strength/distro_b_port_droid_sqi_a_wc
- Ethernet_health_signal_strength/distro_b_port_droid_sqi_a_measure
Troubleshooting Steps
Section titled “Troubleshooting Steps”graph TD
open-the-droid-connection-health-checkin["<small><b>Step 1</b></small><br/>Action: Open the droid-connection-health-che..."]
is-droid-detected-via-load-switch-row-2{"<small><b>Step 2</b></small><br/>Question: Is droid_detected_via_load_switch ..."}
a-droid-is-installed-continue-to-the-nex["<small><b>Step 3</b></small><br/>Action: A Droid is installed."]
there-is-no-droid-installed-which-is-the["<small><b>Step 4</b></small><br/>Action: There is no Droid installed which is ..."]
is-link-status-row-3-solidly-link-up-is{"<small><b>Step 5</b></small><br/>Question: Is link_status row 3 solidly LIN..."}
the-droid-is-on-and-connected-continue-t["<small><b>Step 6</b></small><br/>Action: The Droid is ON and connected. Contin..."]
is-the-link-status-intermittently-toggli{"<small><b>Step 7</b></small><br/>Question: Is the link_status intermittently t..."}
the-droid-has-intermittent-wired-comms-i["<small><b>Step 8</b></small><br/>Action: The Droid has intermittent wired comm..."]
if-the-link-status-is-solidly-down-the-d{"<small><b>Step 9</b></small><br/>Question: If the link_status is solidly DOWN, t..."}
the-aircraft-may-return-to-service("<small><b>Step 10</b></small><br/>Reference: The Aircraft may return to service.")
send-the-droid-to-maintenance-for-mating["<small><b>Step 11</b></small><br/>Action: Send the Droid to maintenance for mat..."]
are-there-messages-from-the-droids-main{"<small><b>Step 12</b></small><br/>Question: Are there messages from the Droid’s m..."}
the-droid-firmware-nodes-are-powered-on["<small><b>Step 13</b></small><br/>Action: The Droid firmware nodes are powered ..."]
droid-power-is-not-in-a-good-state["<small><b>Step 14</b></small><br/>Action: Droid power is not in a good state. 1..."]
are-there-messages-from-the-droid-brain{"<small><b>Step 15</b></small><br/>Question: Are there messages from the Droid bra..."}
the-droid-connection-status-is-healthy-a{{"<small><b>Step 16</b></small><br/>Escalation: The Droid connection status is health..."}}
the-droid-brain-is-unhealthy["<small><b>Step 17</b></small><br/>Action: The Droid brain is unhealthy. 1. Powe..."]
open-the-droid-connection-health-checkin --> is-droid-detected-via-load-switch-row-2
is-droid-detected-via-load-switch-row-2 -->|Yes| a-droid-is-installed-continue-to-the-nex
is-droid-detected-via-load-switch-row-2 -->|No| there-is-no-droid-installed-which-is-the
a-droid-is-installed-continue-to-the-nex --> is-link-status-row-3-solidly-link-up-is
is-link-status-row-3-solidly-link-up-is -->|Yes| the-droid-is-on-and-connected-continue-t
is-link-status-row-3-solidly-link-up-is -->|No| is-the-link-status-intermittently-toggli
the-droid-is-on-and-connected-continue-t --> are-there-messages-from-the-droids-main
is-the-link-status-intermittently-toggli -->|Yes| the-droid-has-intermittent-wired-comms-i
is-the-link-status-intermittently-toggli -->|No| if-the-link-status-is-solidly-down-the-d
if-the-link-status-is-solidly-down-the-d -->|Yes| the-aircraft-may-return-to-service
if-the-link-status-is-solidly-down-the-d -->|No| send-the-droid-to-maintenance-for-mating
are-there-messages-from-the-droids-main -->|Yes| the-droid-firmware-nodes-are-powered-on
are-there-messages-from-the-droids-main -->|No| droid-power-is-not-in-a-good-state
the-droid-firmware-nodes-are-powered-on --> are-there-messages-from-the-droid-brain
are-there-messages-from-the-droid-brain -->|Yes| the-droid-connection-status-is-healthy-a
are-there-messages-from-the-droid-brain -->|No| the-droid-brain-is-unhealthy
style open-the-droid-connection-health-checkin fill:#dcfce7,stroke:#22c55e,color:#14532d
style is-droid-detected-via-load-switch-row-2 fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style a-droid-is-installed-continue-to-the-nex fill:#dcfce7,stroke:#22c55e,color:#14532d
style there-is-no-droid-installed-which-is-the fill:#dcfce7,stroke:#22c55e,color:#14532d
style is-link-status-row-3-solidly-link-up-is fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style the-droid-is-on-and-connected-continue-t fill:#dcfce7,stroke:#22c55e,color:#14532d
style is-the-link-status-intermittently-toggli fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style the-droid-has-intermittent-wired-comms-i fill:#dcfce7,stroke:#22c55e,color:#14532d
style if-the-link-status-is-solidly-down-the-d fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style the-aircraft-may-return-to-service fill:#f3e8ff,stroke:#a855f7,color:#581c87
style send-the-droid-to-maintenance-for-mating fill:#dcfce7,stroke:#22c55e,color:#14532d
style are-there-messages-from-the-droids-main fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style the-droid-firmware-nodes-are-powered-on fill:#dcfce7,stroke:#22c55e,color:#14532d
style droid-power-is-not-in-a-good-state fill:#dcfce7,stroke:#22c55e,color:#14532d
style are-there-messages-from-the-droid-brain fill:#dbeafe,stroke:#3b82f6,color:#1e3a5f
style the-droid-connection-status-is-healthy-a fill:#fef3c7,stroke:#f59e0b,color:#78350f
style the-droid-brain-is-unhealthy fill:#dcfce7,stroke:#22c55e,color:#14532d Hover or focus a block to preview it. Select the block to keep the preview open.
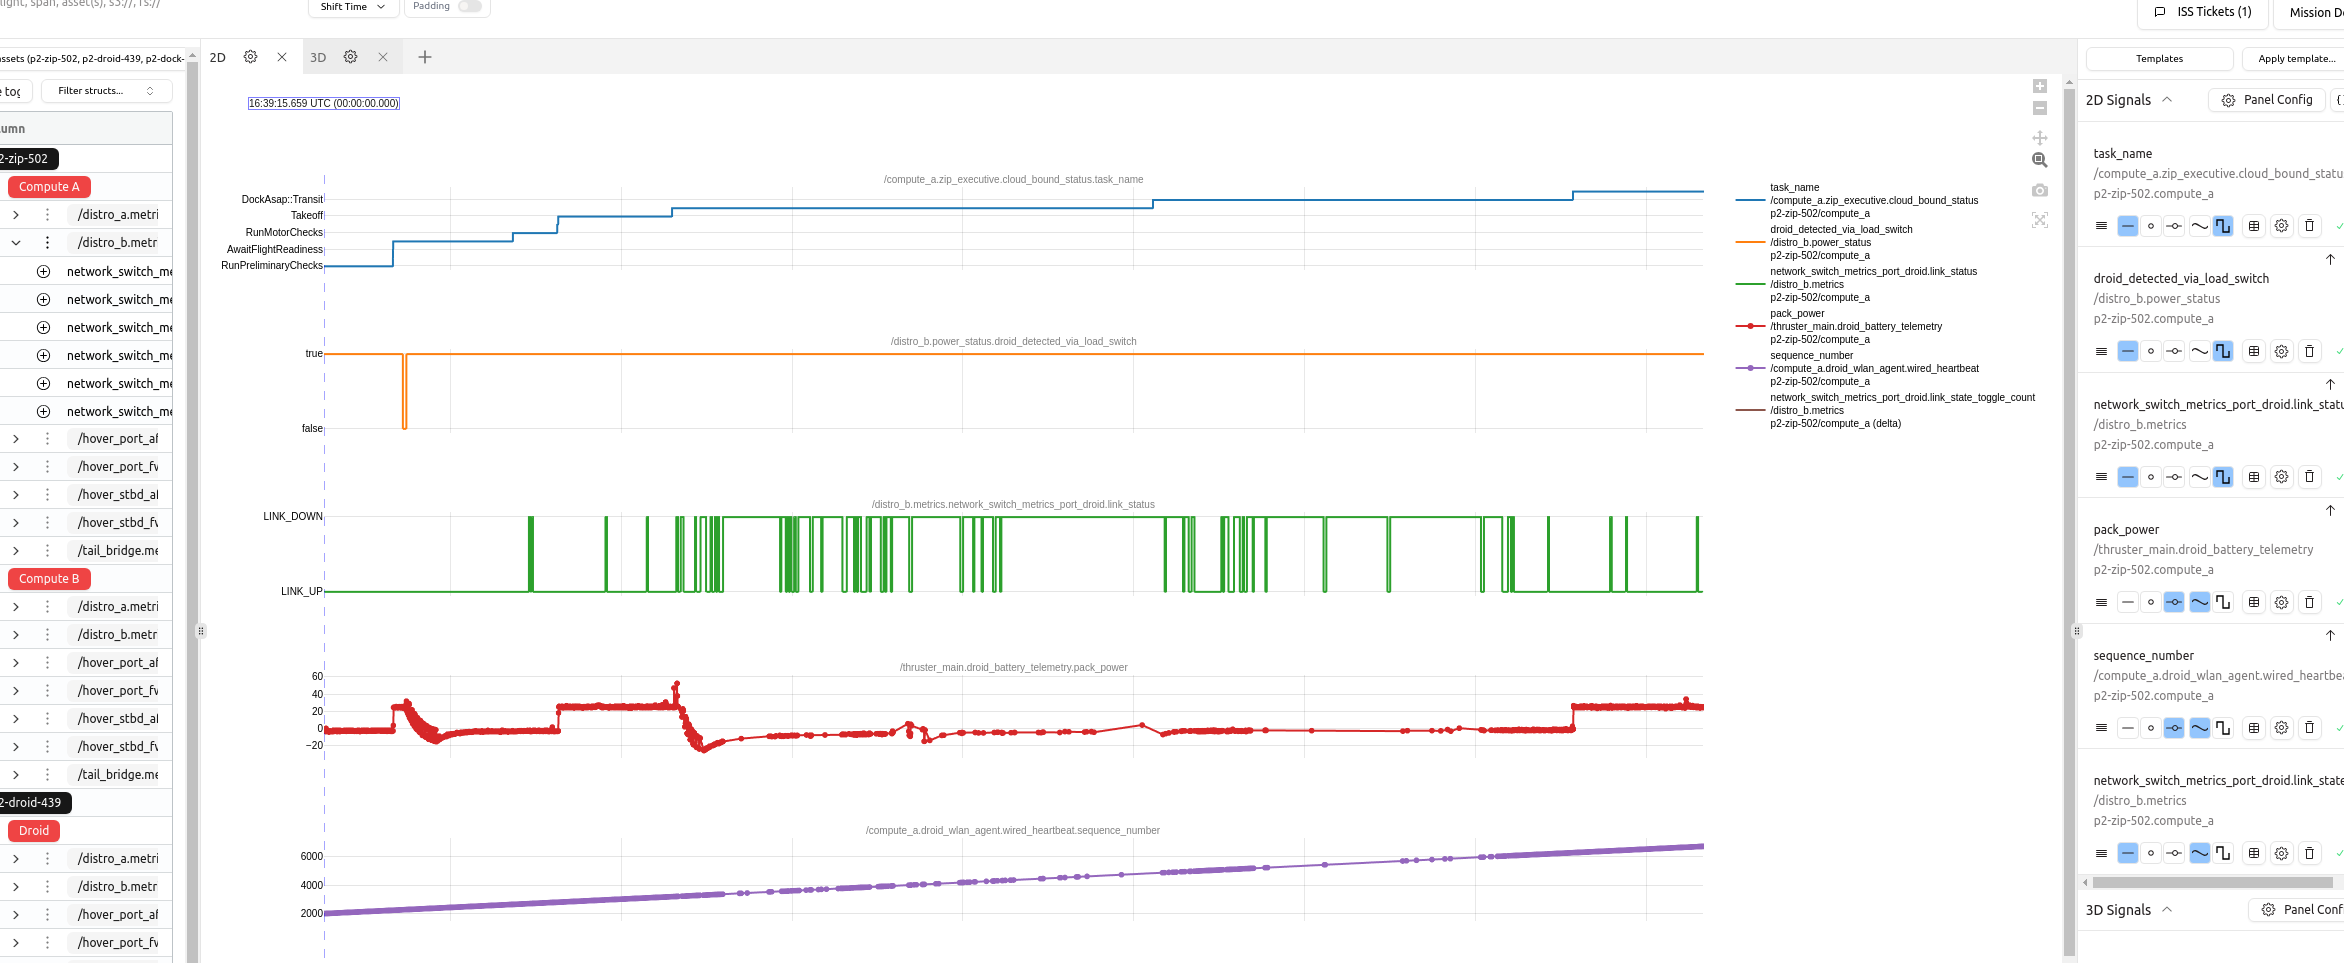
droid_detected_via_load_switch (row 2) TRUE? [Allowing minor blip in RunPreMotorChecks, the above one is pass]1. Install a Droid.
2. Return the Aircraft to service.
link_status (row 3) solidly LINK_UP? [Is it a flat line]Continue to the next step.
link_status intermittently toggling between UP and DOWN? [Is it something like the following]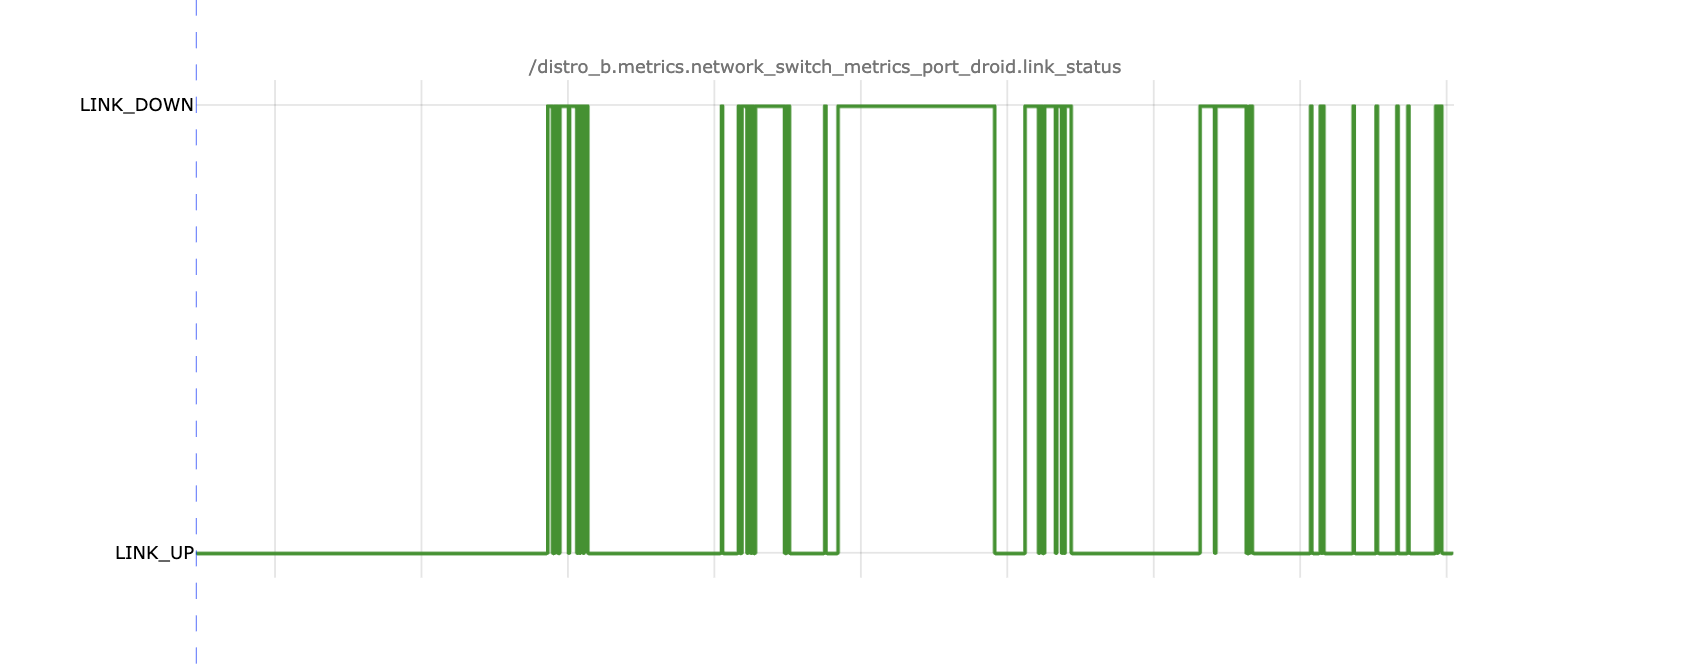
Send the Droid to maintenance for mating connector issues. See Droid to Aircraft Electrical Contacts Debugging.
Power cycle the Droid (Power Cycle Droid).
Is the issue resolved?
Continue to the next step.
1. Power cycle the Droid (Power Cycle Droid).
2. Return the Droid to service.
3. If the issue is not resolved, escalate to p2-firmware-on-call.
Escalate to P2 Droid Autonomy On Call to understand why there are no Droid exec messages.
1. Power cycle the Droid (Power Cycle Droid).
2. Return the Droid to service.
3. If the issue is not resolved, escalate to P2 Embedded Linux On Call.
Resolution note
This plaintext block is ready to paste into the Resolution Note field on the ZERP issue you're working. The permalink below gives engineering review access to the full step-by-step timeline including any back-navigation; share it if the case needs a deeper look.
Permalink:
Session is too large to fit in a URL. Use Download session JSON to share the timeline out-of-band.
Did this guide help you get unblocked?
Open suggestions
There are no open suggestions.
Open pull requests
There are no open pull requests.